X2Real

We present X2Real, an evolvable simulation benchmark for faithfully evaluating the real-world performance of robotic manipulation policies based on Nvidia Isaac Lab-Arena. Following three core principles (faithfulness, diversity, and fairness), X2Real calibrates simulation visual and physical properties to align with real hardware, achieving a 0.84 linear correlation between simulated and real-robot evaluation results. It features a comprehensive taxonomy with 10 capability dimensions and 44 hierarchical long-horizon tasks, covering basic manipulation skills and advanced capacities such as visual grounding, language understanding, and bimanual control. We further adopt multi-axis domain randomization and strictly disjoint training-evaluation pipelines to mitigate benchmark exploitation and ensure credible evaluation.

X2Real

We present X2Real, an evolvable simulation benchmark for faithfully evaluating the real-world performance of robotic manipulation policies based on Nvidia Isaac Lab-Arena. Following three core principles (faithfulness, diversity, and fairness), X2Real calibrates simulation visual and physical properties to align with real hardware, achieving a 0.84 linear correlation between simulated and real-robot evaluation results. It features a comprehensive taxonomy with 10 capability dimensions and 44 hierarchical long-horizon tasks, covering basic manipulation skills and advanced capacities such as visual grounding, language understanding, and bimanual control. We further adopt multi-axis domain randomization and strictly disjoint training-evaluation pipelines to mitigate benchmark exploitation and ensure credible evaluation.

2026.10.13
X2Real

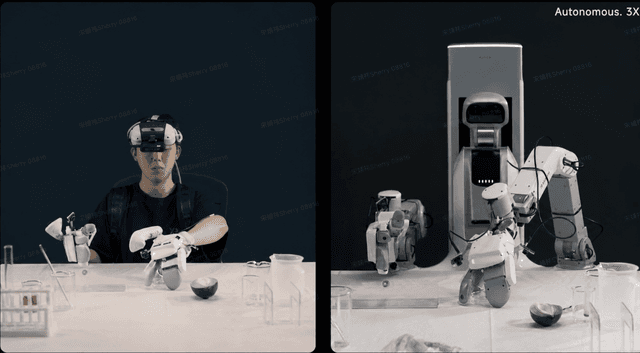
TwinDEX

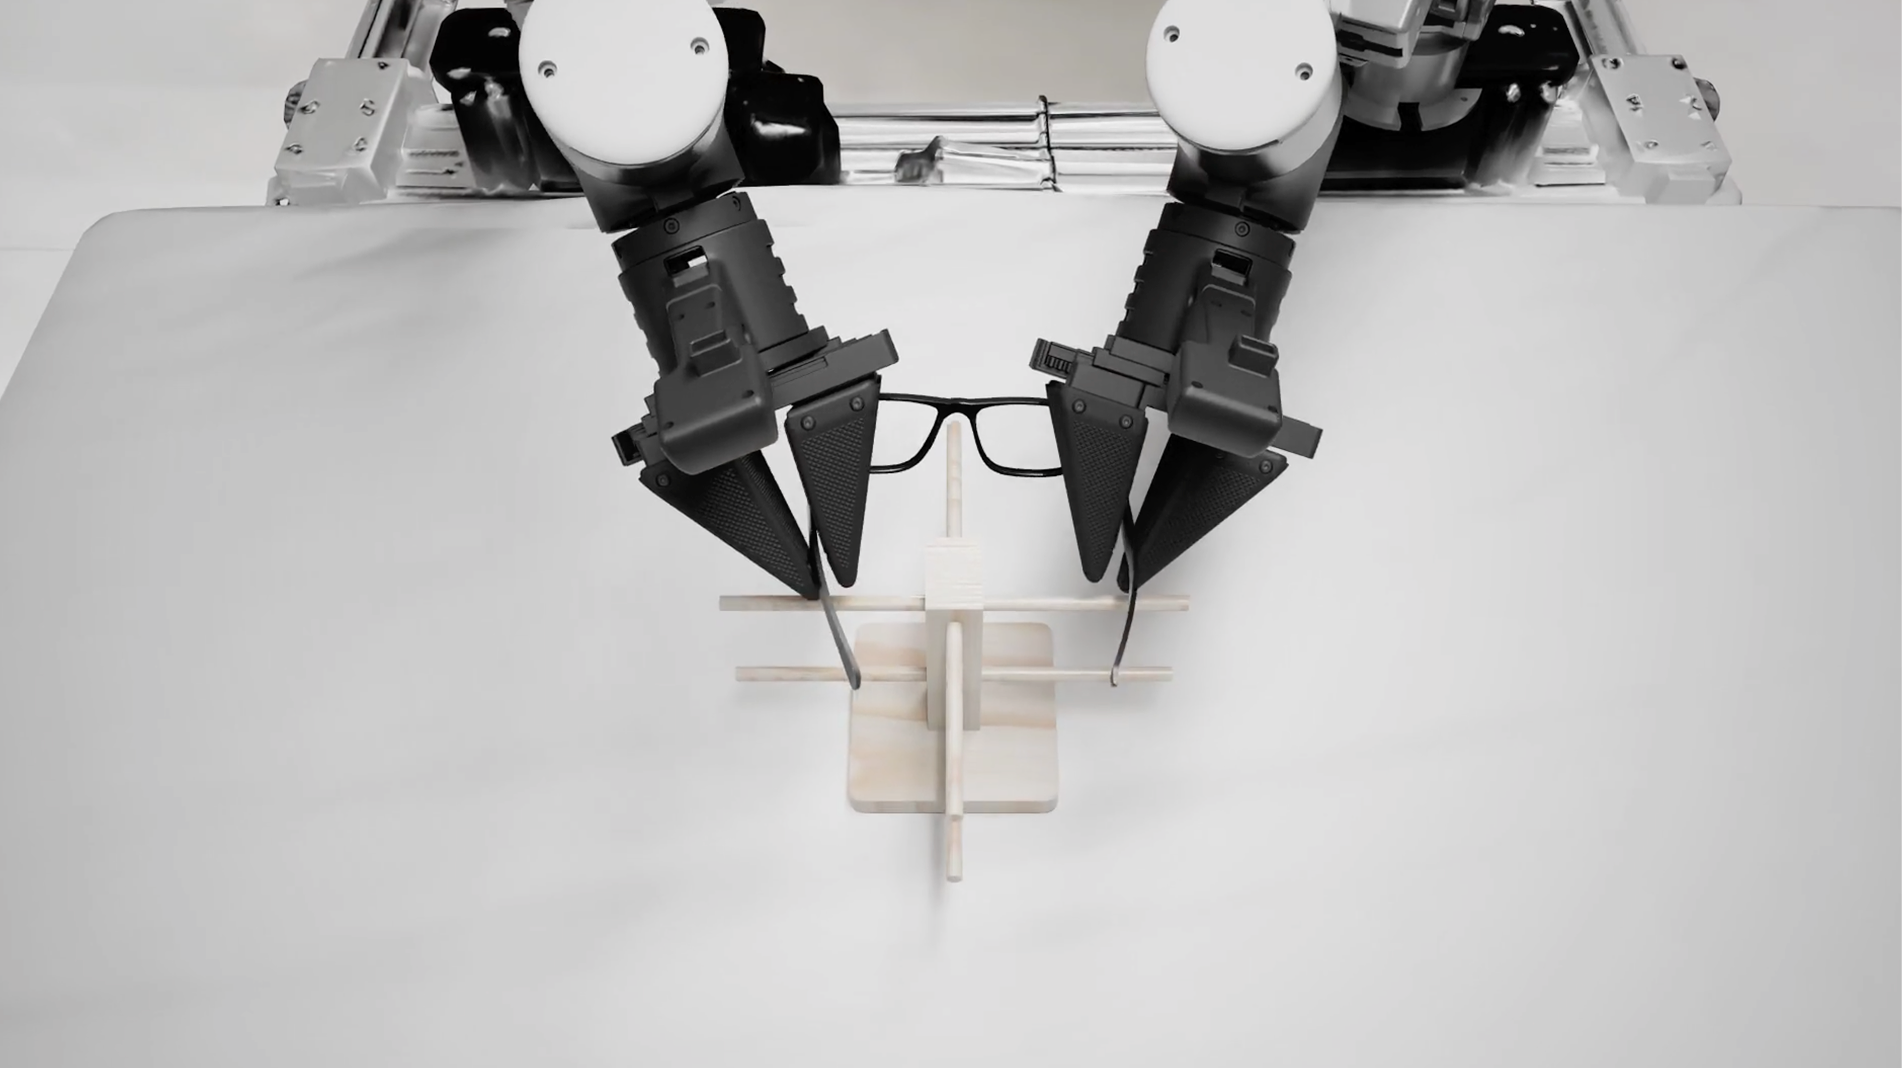
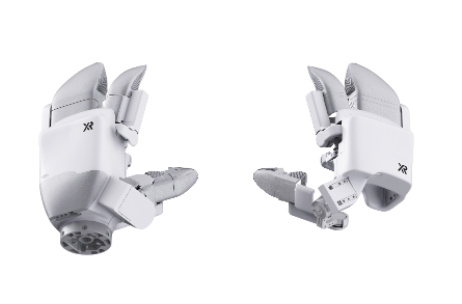
A pair of co-designed, three-finger, nine-DoF dexterous manipulation interface: one wearable for data collection, one for robot deployment.

2026.09.02
TwinDEX

WALL-SS

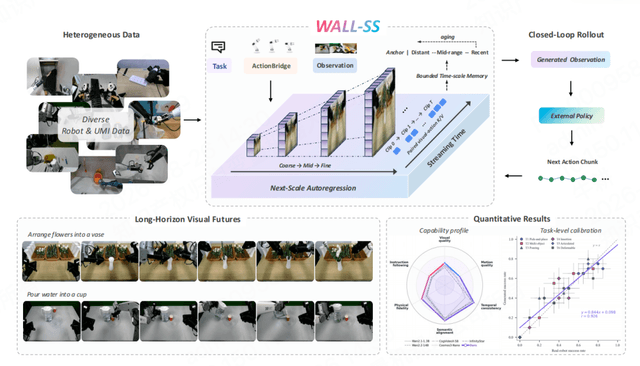
A generative world model for action-controllable, long-horizon robotic simulation. Built on next-scale autoregression with scale-compressed streaming memory and on-policy alignment, it generates visual futures in a coarse-to-fine manner, achieving calibrated task outcomes and consistent policy rankings across 600+ matched sim-to-real closed-loop rollouts.

2026.08.27
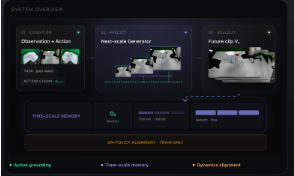
WALL-SS

Human-to-robot One-Shot Skill Acquisition (HOST)

A training-free framework that enables robots to acquire new manipulation skills in seconds from a single human video while retaining previously mastered capabilities.

2026.08.03
Human-to-robot One-Shot Skill Acquisition (HOST)

X-Tokenizer

A multimodal action tokenizer that doubles as a semantic interface between vision-language reasoning and continuous robot control.

2026.06.30
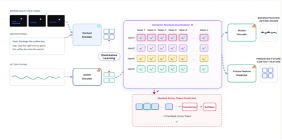
X-Tokenizer

XRZero-G0

XRZero-G0 is an embodied data acquisition and strategy learning system designed through deep collaboration between hardware and software. It aims to overcome the fundamental bottleneck of acquiring high-quality, motion-aligned demonstration data in the field of dexterous robot operation.

2026.06.10
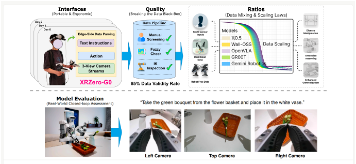
XRZero-G0

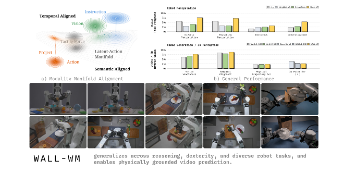
WALL-WM

Carving World Action Modeling at the Event Joints

2026.05.29
WALL-WM

WALL-OSS-0.5

fully open-source, trained with gradient-bridged co-training, and deployable on real robots straight from pretraining.

2026.05.28
WALL-OSS-0.5

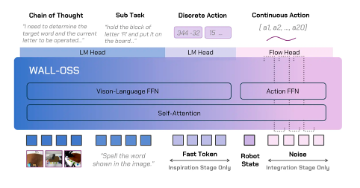
WALL-OSS

An end-to-end embodied foundation model that leverages large-scale multimodal pretraining to achieve (1) embodiment-aware vision--language understanding, (2) strong language--action association, and (3) robust manipulation capability.

2025.09.08
WALL-OSS
Providing an Intelligent
Singularity Spanning the Physical World

X Square Robot develops general-purpose embodied intelligence robots with high-precision manipulation capabilities. We are one of China's first companies to pioneer end-to-end solutions for general-purpose embodied intelligence.

Our WALL-A model, part of the Great Wall embodied foundation model series, integrates autonomous perception, decision-making, and high-precision manipulation, demonstrating world-leading performance across multiple scenarios.

X Square Robot adheres to a philosophy of tightly integrating hardware-software iterative development, including independent design and constant refinement of our robotic platforms to optimize for multimodal large-model control. This ensures the highest precision manipulation and stable performance in open real-world environments.

Our robots are currently deployed in scenarios requiring complex, multi-step task execution.

About Us

测试

A unified foundation model
as a cross-domain, multi-modal intelligent embodied platform

Our WALL-A model integrates perception, reasoning, and precision manipulation
using a unified framework of generalized understanding and manipulation.

We have achieved total automation with high precision by breaking through the rules and limitations of robotics programming.

Model Research

End-to-End Structure

Billion-scale Parameters

Generalization Across Tasks & Scenarios

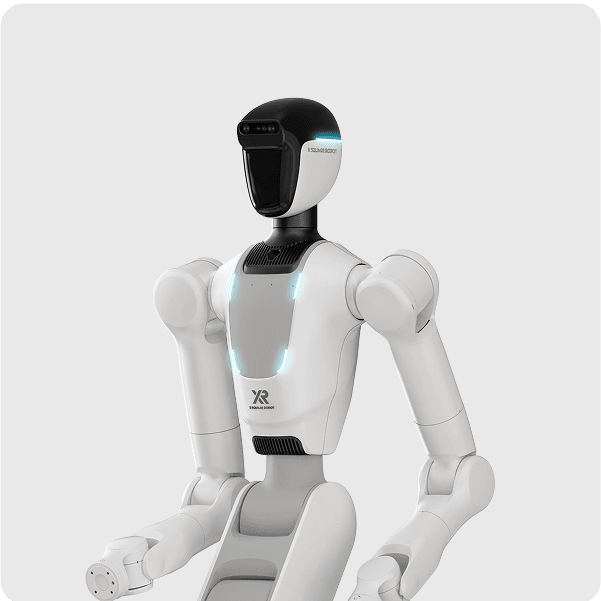
Quanta X2

Next‑Generation General-Purpose Wheeled Humanoid Robot

Learn More
End-to-End Embodied Generalization
End-to-end embodied foundation model architecture
Perception-Decision-Action Cycle
Supports cross-modal reasoning in the real world
High generalization and adaptability
Hardware & Software Integration
Model-driven high-DOF arm coordination design
Full-body motion control with human-level flexibility
High-dynamic force-control safety design
Model-native hardware interface design
High Environmental Adaptability
Exceptional ground mobility for diverse terrains
Humanoid-style workspace for natural interaction
Smooth audio-visual perception for seamless human-robot communication
Flexible tool usage for versatile tasks

General‑Purpose Wheeled Bimanual Robot

Quanta X1 PRO

Next‑Generation General‑Purpose Wheeled Humanoid Robot

Quanta X2

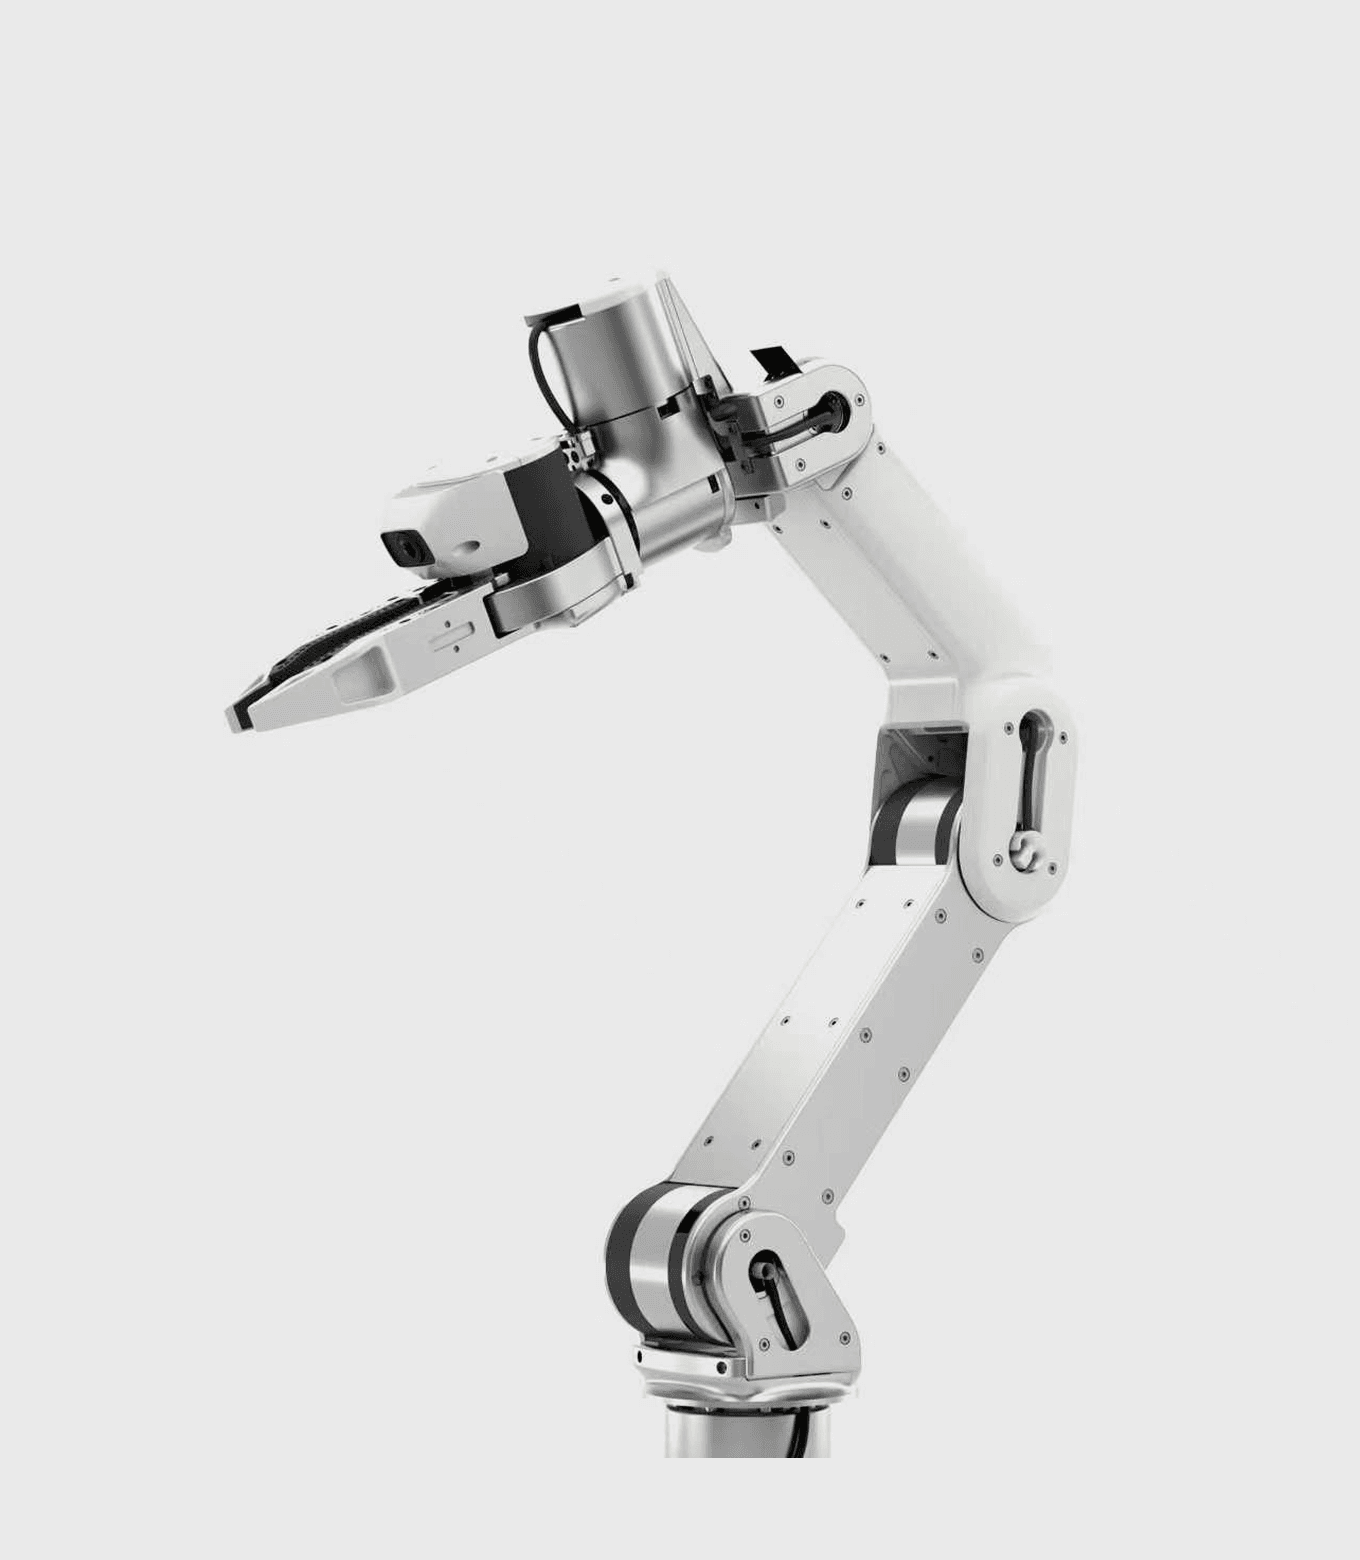
High-Performance 6-Axis Robotic Arm

ArtiXon Arm-6A

Multi-Scenario
Intelligent Robotic Solutions
WALL-A: Smarter, Autonomous, Everywhere

Breaking free from traditional programming, WALL-A tackles complex environments using high-precision autonomy, making intelligent robotics instantly practical.

  • Home-based Services
  • Research & Education
  • Commercial Cleaning
  • Logistics Sorting

News