数据采集示例
采集数据
使用该示例采集的数据可以通过我们提供的转换脚本转成 lerobot 格式, 便于用户进行训练
"""
Data Collection Example

This script demonstrates how to use DataCollector to collect robot data
"""

import time
from typing import Annotated
from pathlib import Path
import typer
import signal
import sys

# Add current directory to Python path (to import data_collection module)
sys.path.insert(0, str(Path(__file__).parent))

from data_collection.data_collector import DataCollector
from data_collection.collection_config import CollectionConfig
from x2robot import connect

def signal_handler(sig, frame):
    """Handle Ctrl+C signal"""
    print("\n\nReceived interrupt signal, stopping...")
    # Note: DataCollector has already registered a signal handler to clean up temporary files
    # Just exit here, cleanup work is done by DataCollector's signal handler
    sys.exit(0)

def create_collection_config_for_quanta_x1() -> CollectionConfig:
    # Do not set SDK mode
    collection_config = CollectionConfig()

    collection_config.slave_joint_names = [
        'left_arm_joint_states',
        'right_arm_joint_states',
        'lift_joint_states',
        'left_gripper_joint_states',
        'right_gripper_joint_states',
        'head_joint_states'
    ]
    # action_names will be generated automatically from joint_names, or can be specified manually
    collection_config.enable_head_rgb_stream = True # Collect head RGB video stream
    collection_config.enable_left_arm_rgb_stream = True # Collect left arm RGB video stream
    collection_config.enable_right_arm_rgb_stream = True # Collect right arm RGB video stream
    collection_config.enable_left_arm_end_pose = True # Collect left arm end pose
    collection_config.enable_right_arm_end_pose = True # Collect right arm end pose
    collection_config.enable_odometry = True # Collect odometry data
    collection_config.enable_master_arm_data = True # Collect master arm joint states and end pose
    collection_config.enable_wrench_ext_world = True # Collect wrist external force
    collection_config.enable_wrench_ext_local = True # Collect wrist local force

    return collection_config

def create_collection_config_for_quanta_x2() -> CollectionConfig:
    collection_config = CollectionConfig()
    collection_config.slave_joint_names = [
        'left_arm_joint_states',
        'right_arm_joint_states',
        'waist_joint_states',
        'head_joint_states'
    ]
    # action_names will be generated automatically from joint_names, or can be specified manually
    collection_config.enable_head_rgb_stream = True # Collect head RGB video stream
    collection_config.enable_left_arm_rgb_stream = True # Collect left arm RGB video stream
    collection_config.enable_right_arm_rgb_stream = True # Collect right arm RGB video stream
    collection_config.enable_left_arm_end_pose = True # Collect left arm end pose
    collection_config.enable_right_arm_end_pose = True # Collect right arm end pose
    collection_config.enable_left_gripper_position = True # Collect left gripper position
    collection_config.enable_right_gripper_position = True # Collect right gripper position
    collection_config.enable_odometry = True # Collect odometry data

    collection_config.enable_waist_end_pose = True # Collect waist end pose

    # No master arm joint states and end pose
    # No wrist external and local force
    # Has tactile sensor data
    collection_config.enable_left_gripper_tactile = True # Collect left finger tactile sensor data
    collection_config.enable_right_gripper_tactile = True # Collect right finger tactile sensor data
    return collection_config

def create_collection_config_for_desktop() -> CollectionConfig:
    collection_config = CollectionConfig()
    # Collect slave arm joint states (Desktop model, only left and right arms)
    collection_config.slave_joint_names = [
        'left_arm_joint_states',
        'right_arm_joint_states',
        'left_gripper_joint_states',
        'right_gripper_joint_states'
    ]
    # action_names will be generated automatically from joint_names, or can be specified manually
    collection_config.enable_head_rgb_stream = True # Collect head RGB video stream
    collection_config.enable_left_arm_rgb_stream = True # Collect left arm RGB video stream
    collection_config.enable_right_arm_rgb_stream = True # Collect right arm RGB video stream
    collection_config.enable_left_arm_end_pose = True # Collect left arm end pose
    collection_config.enable_right_arm_end_pose = True # Collect right arm end pose
    return collection_config

def main(
    server: Annotated[str, typer.Option(help="server address, e.g., localhost:50051")] = "localhost:50051",
):
    # Register signal handler
    signal.signal(signal.SIGINT, signal_handler)

    # Connect to robot
    print(f"Connecting to robot {server}...")
    robot = connect(f"x2://{server}")
    print("✓ Robot connected successfully")

    if robot.get_robot_model() == "quanta_x1":
        collection_config = create_collection_config_for_quanta_x1()
    elif robot.get_robot_model() == "quanta_x2":
        collection_config = create_collection_config_for_quanta_x2()
    elif robot.get_robot_model() == "desktop":
        collection_config = create_collection_config_for_desktop()
    else:
        raise ValueError(f"Invalid model: {robot.get_robot_model()}, valid models: quanta_x1, quanta_x2, Desktop")

    # Create data collector - optimize configuration to improve performance
    collector = DataCollector(
        robot=robot,
        output_dir="./collected_data",
        target_hz=30,                      # Target frequency (after downsampling)
        collection_config=collection_config,
        image_quality=95,                  # JPEG quality
        downsample_joint_states=True,       # Whether to downsample joint states, recommended to enable (eg: 500Hz -> target_hz=60Hz)
        use_video_storage=True
    )

    print("\n" + "="*60)
    print("Data collector is ready")
    print("="*60)
    print(f"Output directory: {collector.output_dir}")
    print(f"Target frequency: {collector.target_hz} Hz")
    print(f"Image storage: {'MP4 video' if collector.use_video_storage else 'JPG image'}")
    print("\nTips:")
    print("  - start_recording() will start all data collection threads automatically")
    print("  - stop_recording() will stop all threads automatically and save data")
    print("  - press Ctrl+C to interrupt the program at any time")
    print("="*60 + "\n")

    try:
        # Record multiple episodes
        episode_index = 0
        while True:
            # Show current episode number to record (based on number of existing episodes)
            current_episode_num = collector.episode_count
            print(f"\n{'='*60}")
            print(f"Ready to record Episode {current_episode_num}")
            print(f"{'='*60}")

            # Ask for task name
            task_name = input("Enter task name (e.g.: pick_trash, press Enter to use default name): ").strip()
            if not task_name:
                task_name = "pick_trash"

            print(f"\nTask name: {task_name}")
            print("Please prepare the robot, press Enter to start recording...")
            input()

            # Start recording (will start all data collection threads automatically)
            print("\n" + "="*60)
            print("Start recording...")
            print("="*60)
            collector.start_recording(task=task_name)

            print("\n✓ All data collection threads have been started")
            print("Recording in progress...")
            print("Tips: execute your task, press Enter to stop recording")
            print("      (or press Ctrl+C to interrupt current recording)\n")

            # Print statistics every second
            recording_interrupted = False
            while True:
                try:
                    # Non-blocking input detection
                    import select
                    if select.select([sys.stdin], [], [], 1)[0]:
                        input()  # Read input
                        break

                    # Print statistics
                    collector.print_stats()
                except KeyboardInterrupt:
                    print("\n\nReceived interrupt signal, stopping recording...")
                    recording_interrupted = True
                    break

            # Stop recording (will stop all data collection threads automatically)
            episode_info = None
            if collector.is_recording:
                episode_info = collector.stop_recording()

            if episode_info:
                episode_id = episode_info['episode_id']
                print(f"\n{'='*60}")
                print(f"✓ Episode {episode_id} recording completed!")
                print(f"{'='*60}")
                print(f"  - Episode ID: {episode_id}")
                print(f"  - Task name: {episode_info.get('task', task_name)}")
                print(f"  - Number of frames: {episode_info['num_frames']}")
                print(f"  - Duration: {episode_info['duration']:.2f}s")
                print(f"  - Save path: {episode_info['episode_dir']}")
            else:
                current_episode_num = collector.episode_count
                print(f"\n⚠️  Episode {current_episode_num} recording failed")

            if recording_interrupted:
                print("\nRecording interrupted")
                break

            # Ask whether to continue recording
            print("\n" + "-"*60)
            continue_recording = input("Continue recording next episode? (y/n, default n): ").strip().lower()
            if continue_recording != 'y':
                print("Stop recording")
                break

            episode_index += 1

    except KeyboardInterrupt:
        print("\n\nReceived interrupt signal, stopping...")
    except Exception as e:
        print(f"\nError: {e}")
        import traceback
        traceback.print_exc()
    finally:
        # Ensure stopping recording (if still recording)
        if collector.is_recording:
            print("\nStopping recording...")
            collector.stop_recording()

        print("\n" + "="*60)
        print("Data collection completed!")
        print("="*60)
        print(f"Total {collector.episode_count} episodes recorded")
        print(f"Data saved in: {collector.output_dir}")
        print(f"\nConvert to LeRobot format:")
        print(f"python3 tools/convert_to_lerobot.py \\")
        print(f"    --input-dir {collector.output_dir} \\")
        print(f"    --output-dir ./lerobot_data \\")
        print(f"    --repo-id my_robot/dataset \\")
        print(f"    --robot-type {robot.get_robot_model()} \\")
        print(f"    --use-videos")

if __name__ == "__main__":
typer.run(main)数据采集对网络带宽要求较高,请先按照网络配置章节配置好有线网络后再进行数据采集
数采使用示例:
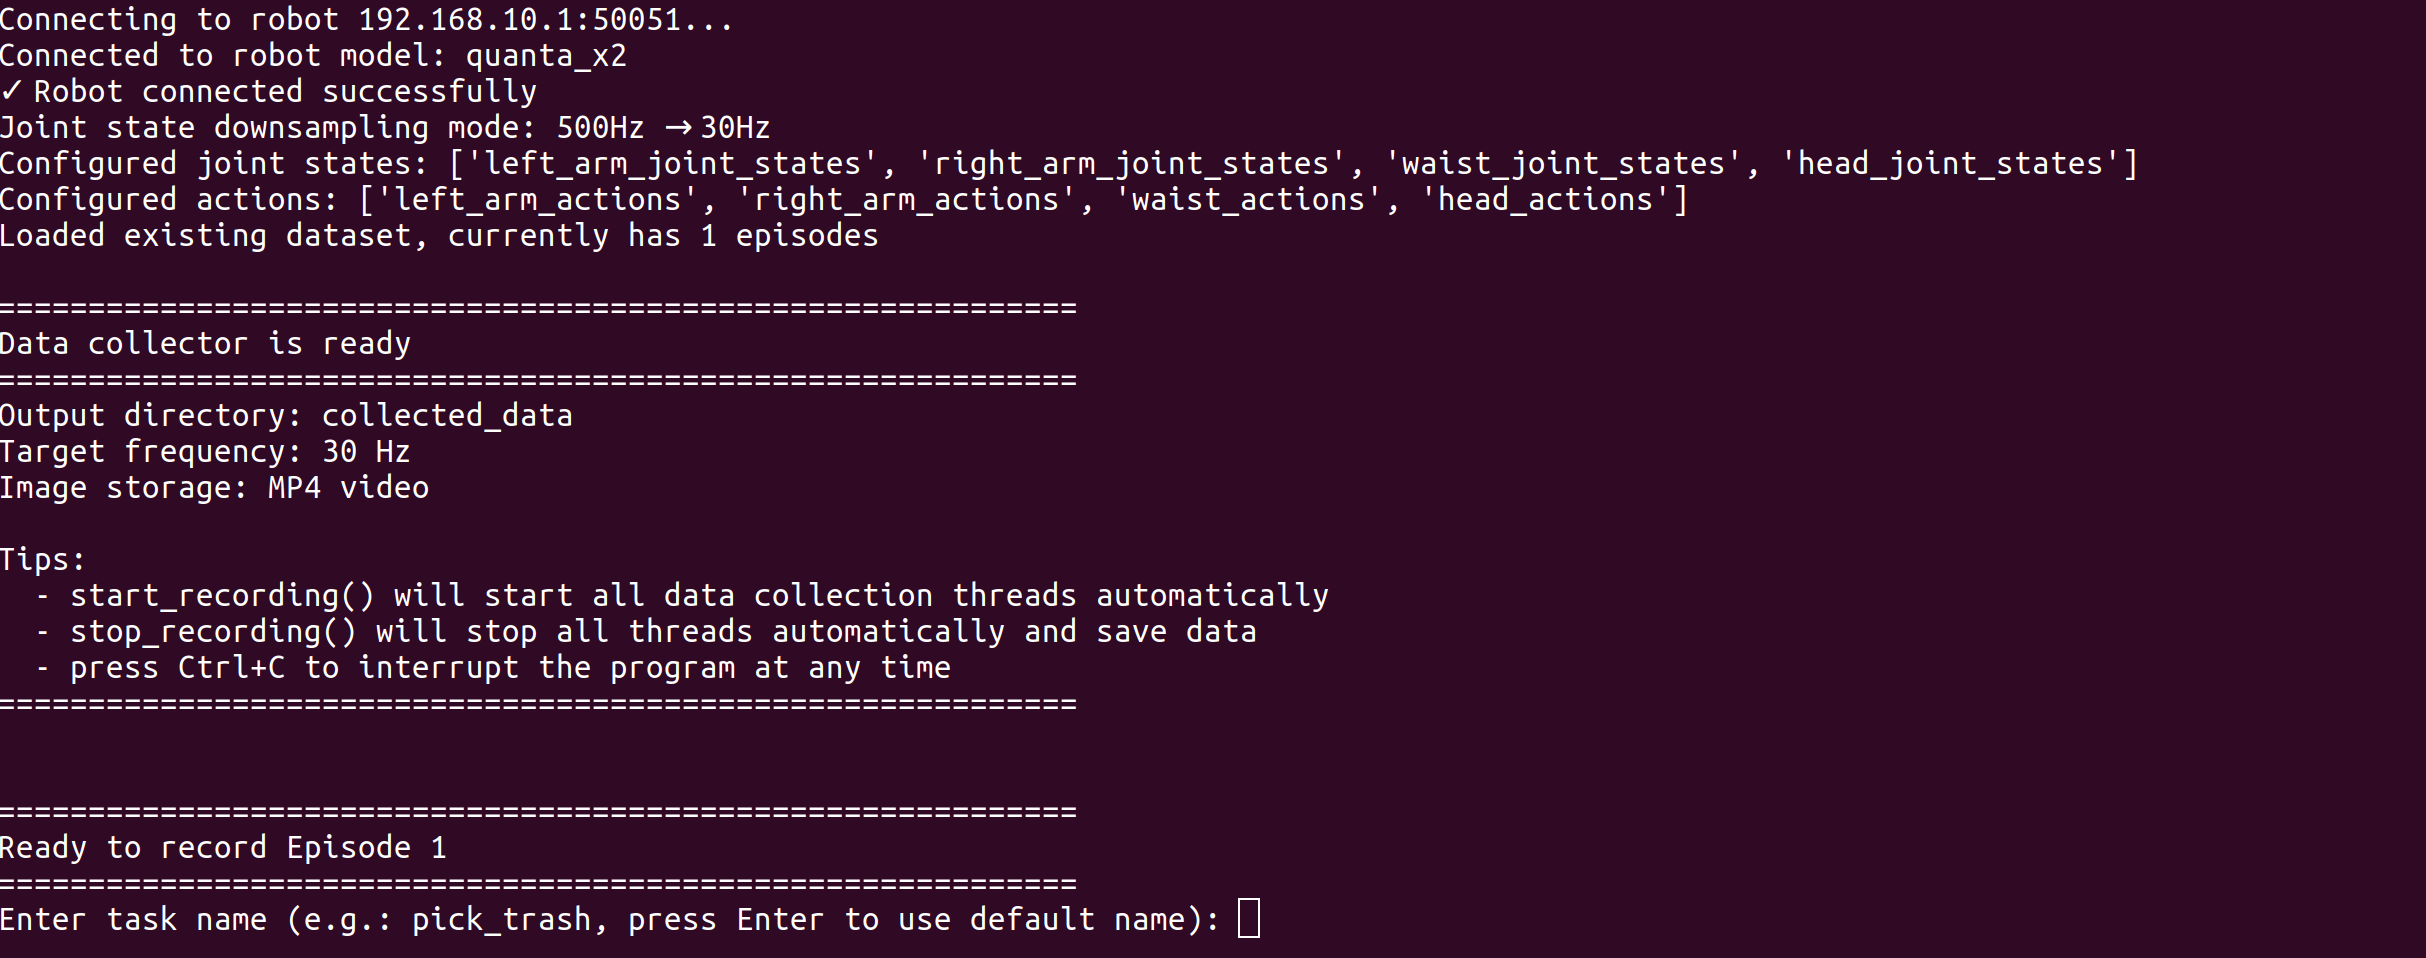
python3 examples/data_collection_example.py --server 192.168.10.1:50051提示输入任务名称:不输就是默认名称 pick_trash
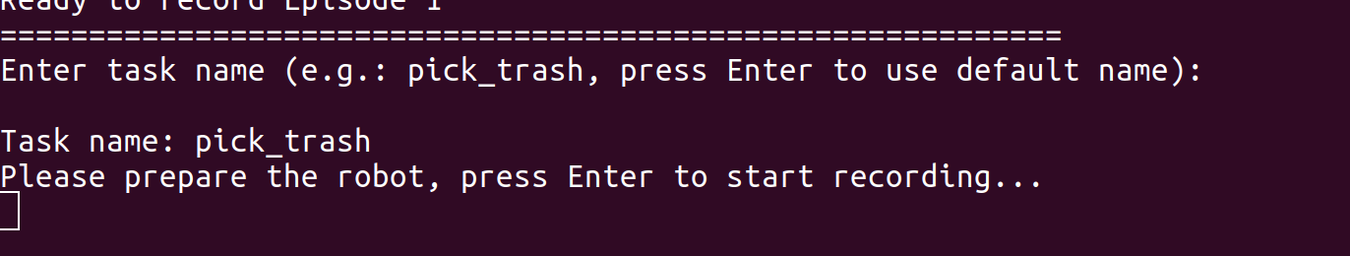
输入任务名称之后再次按 Enter 开始录制
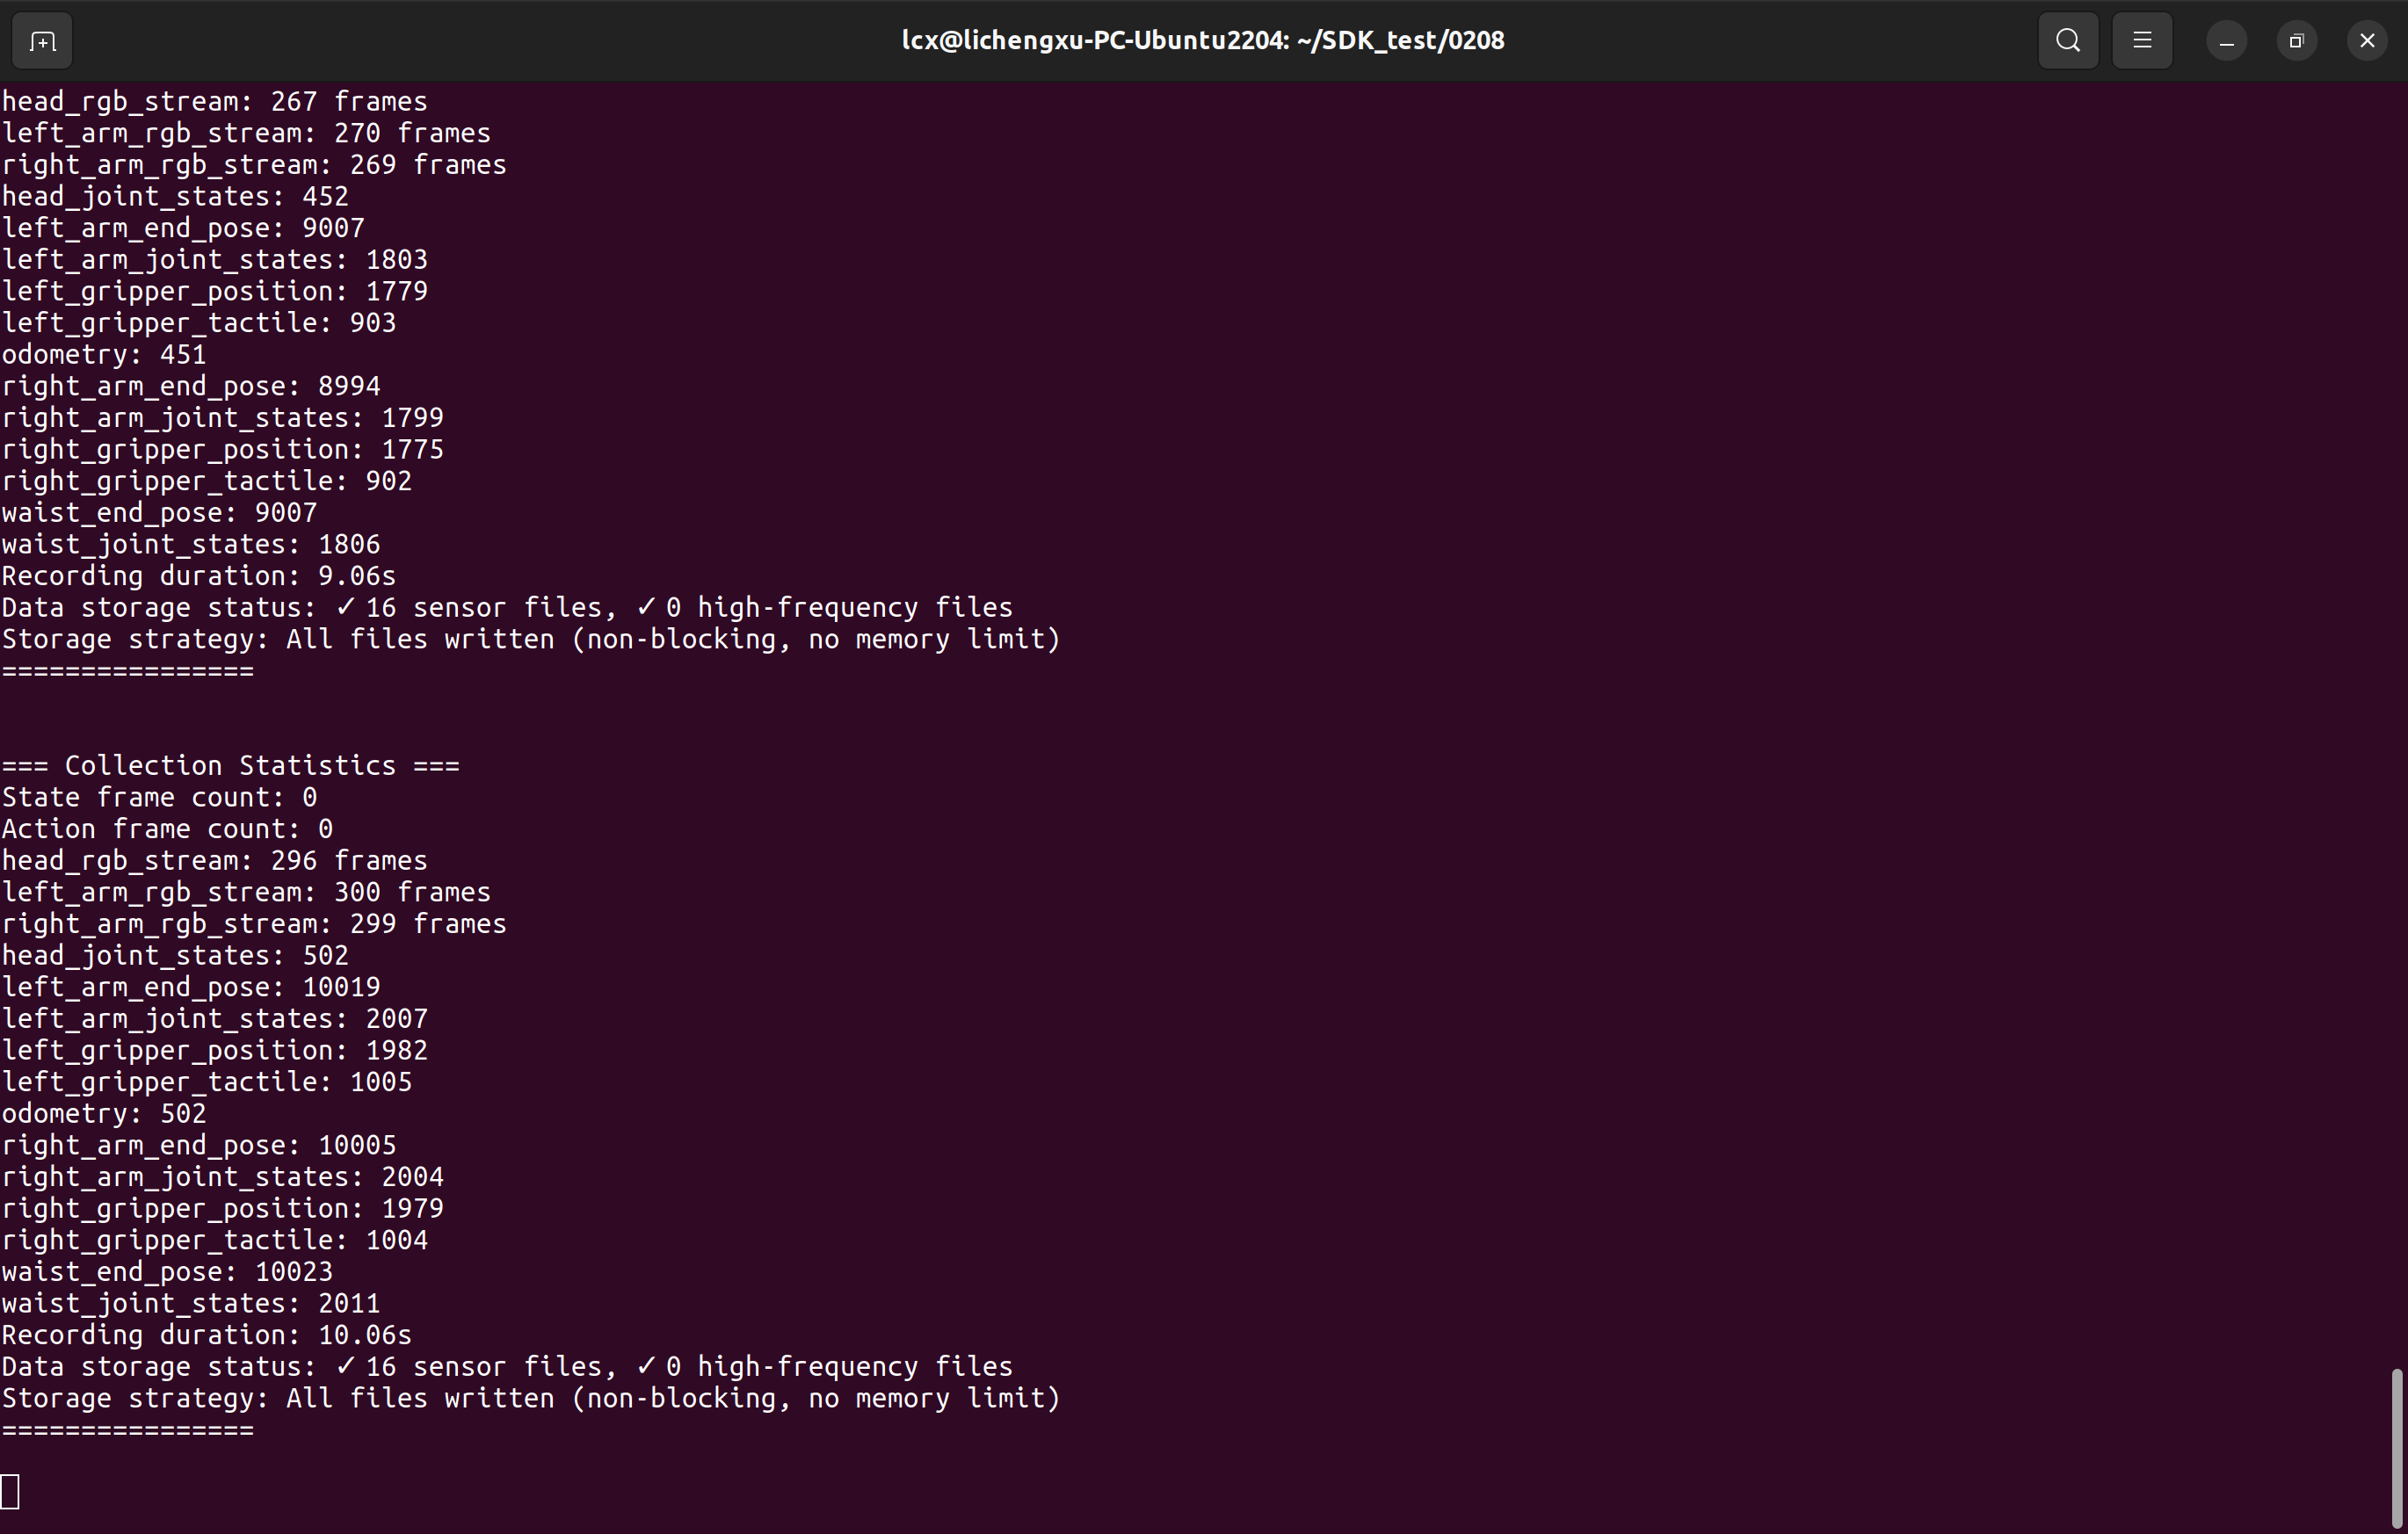
开始采集和录制一个 Episode,每秒更新一次统计
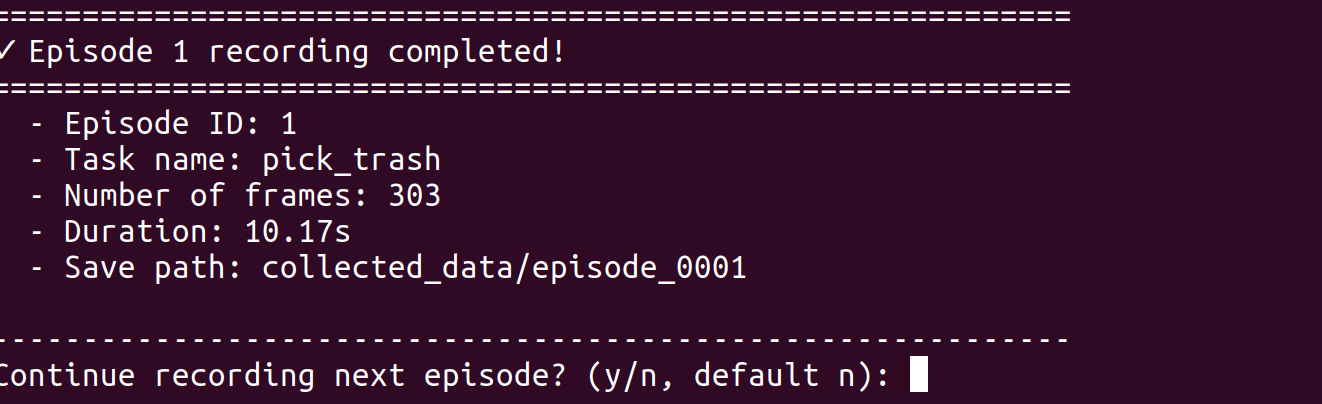
再次按 Enter 键停止本 Episode 录制,提示下面框选的信息则表示当前 Episode 已经录制成功
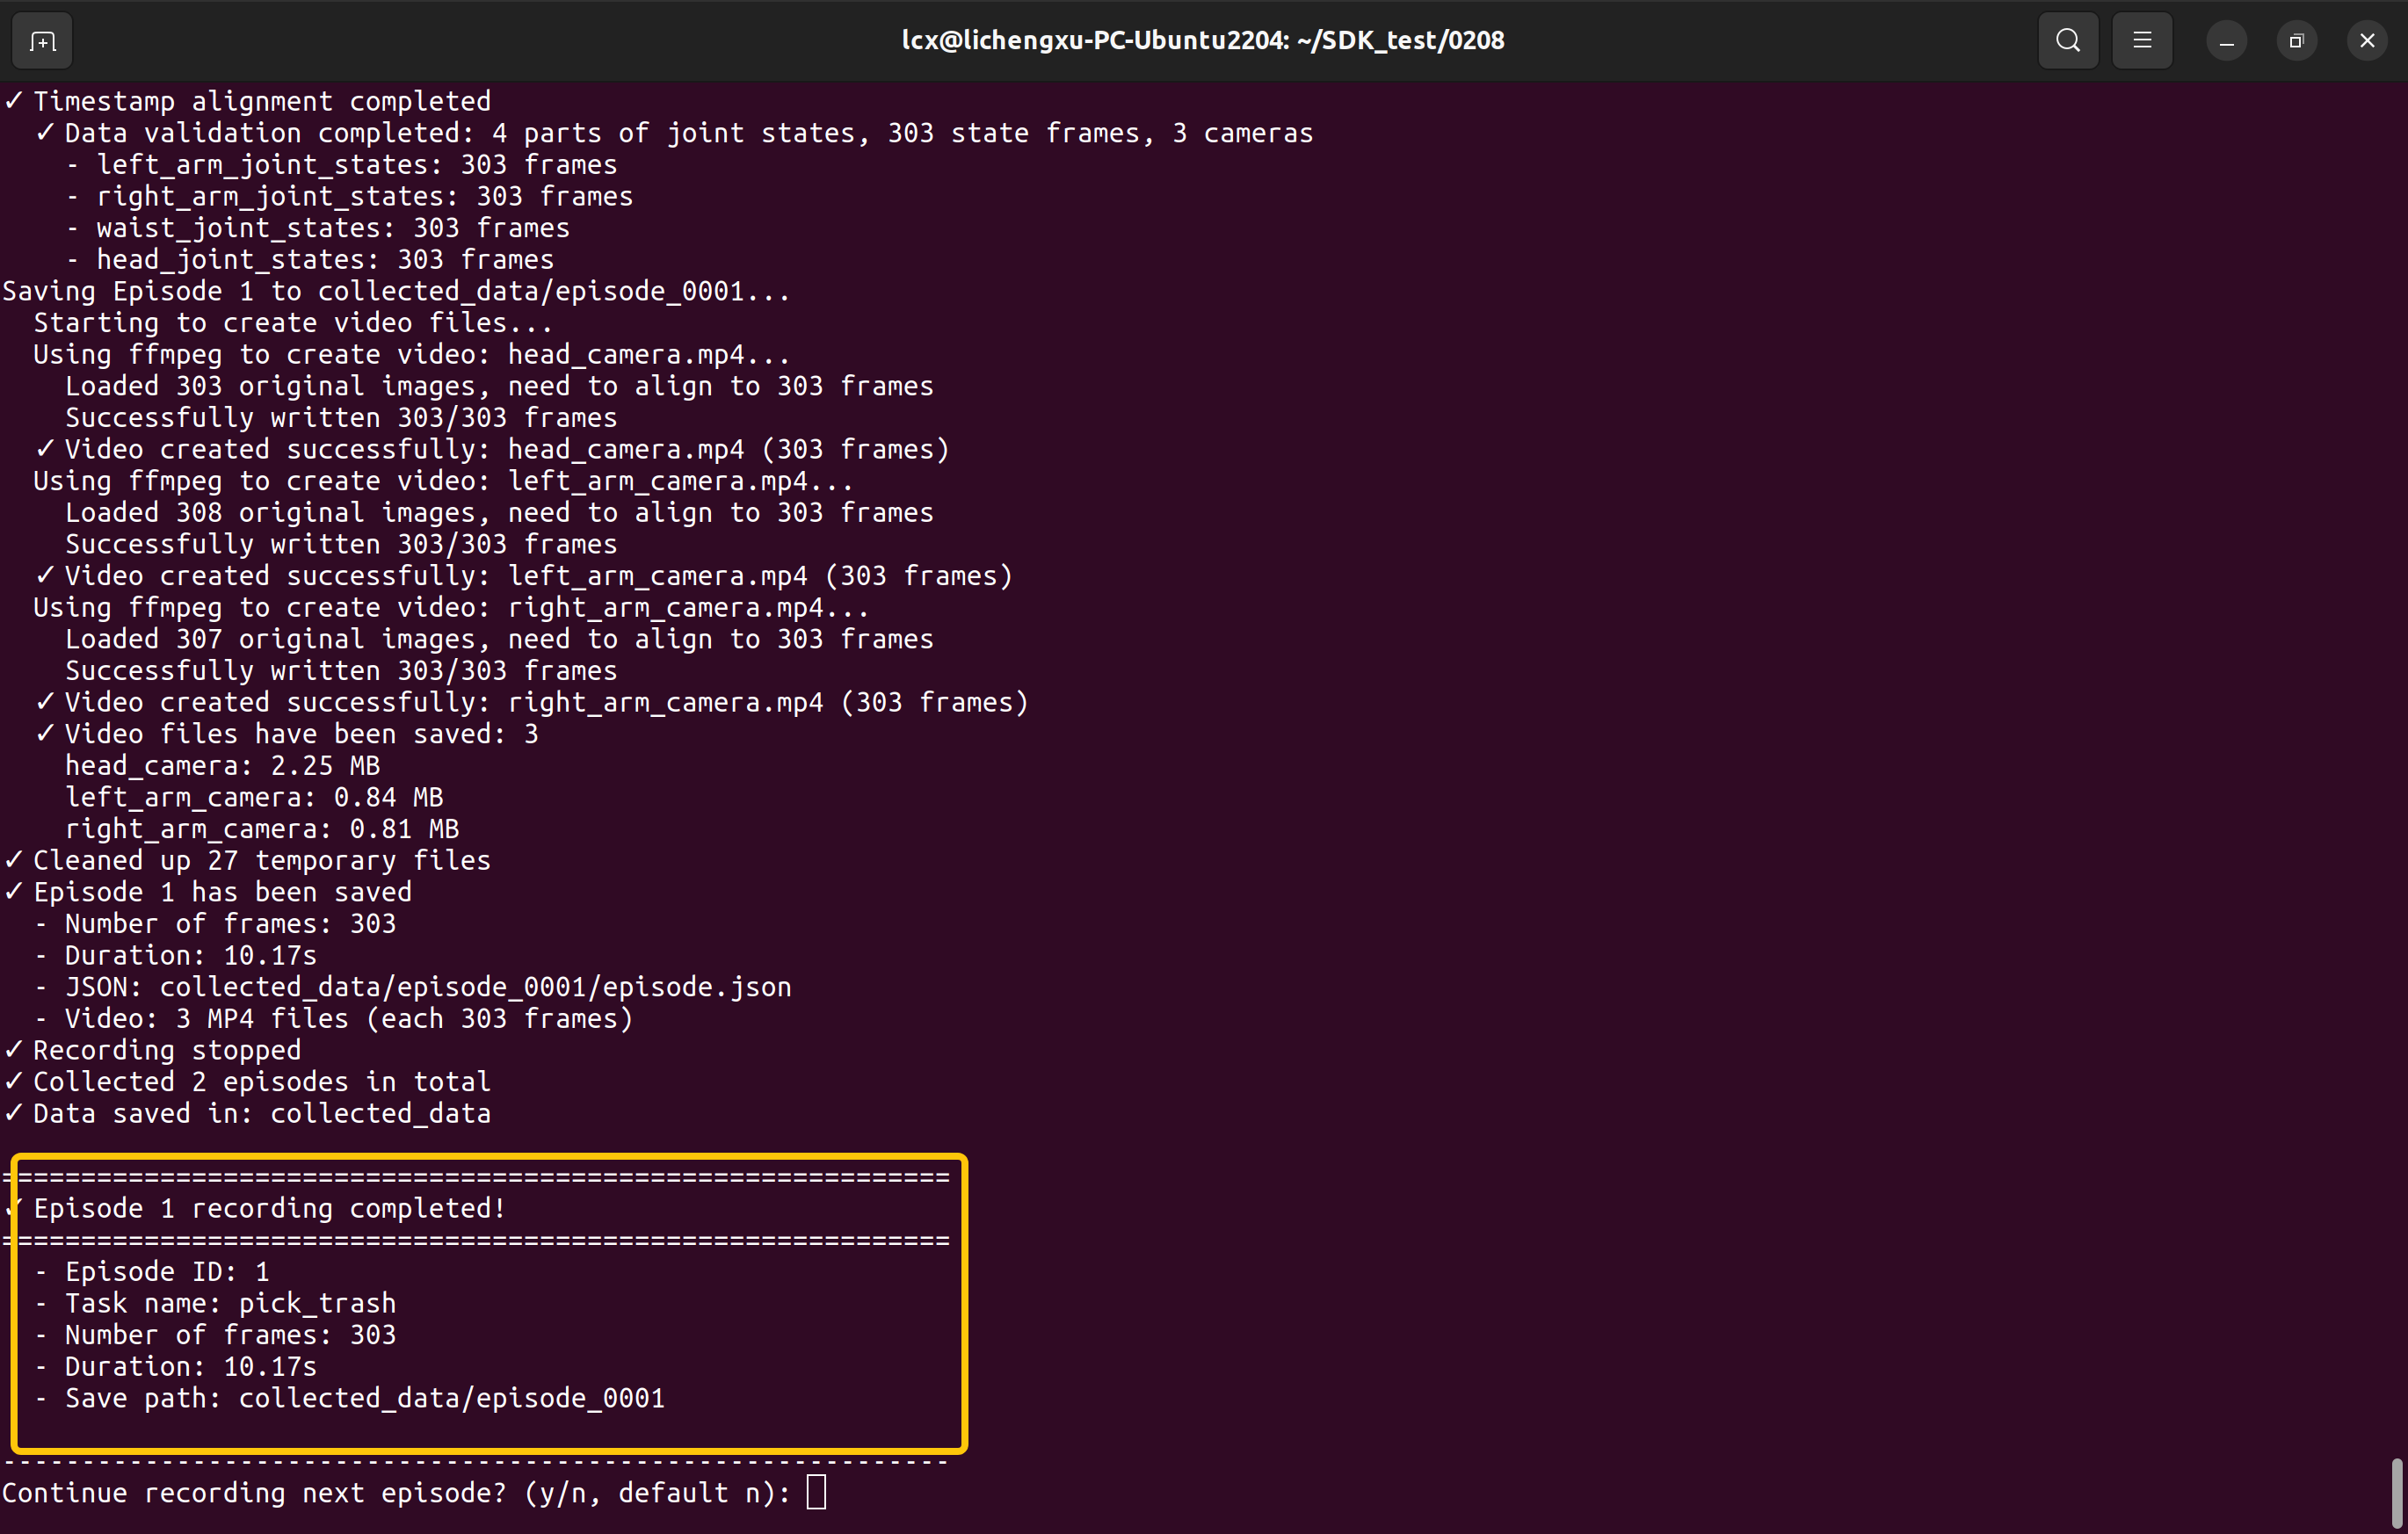
等待数据处理完成之后,可以选择继续录制下个 Episode 或者停止录制
数据回放
数据回放需要将主臂端切到空闲模式
成功切到空闲模式后,执行 examples 下面的 data_replay_example.py 脚本,可以指定要回放的 episode 和回放模式(关节位置控制还是末端位姿控制)
python3 examples/data_replay_example.py ./collected_data/episode_0003/ --server 192.168.10.1:50051 --mode end_pose转换数据到 lerobot 格式
我们提供了将通过 DataCollector 采集的数据转换成 lerobot 格式的脚本
使用该脚本之前需要先安装 lerobot 依赖
https://github.com/huggingface/lerobot/releases/download/v0.4.2/lerobot-0.4.2-py3-none-any.whl
安装之前记得也要激活虚拟环境
pip install lerobot-0.4.2-py3-none-any.whl安装需要一段时间, 完成后使用 convert_to_lerobot.py 脚本进行转换
python3 tools/convert_to_lerobot.py \
    --input-dir collected_data \
    --output-dir ./lerobot_data \
    --repo-id my_robot/dataset \
    --robot-type quanta_x1 \
    --use-videos