

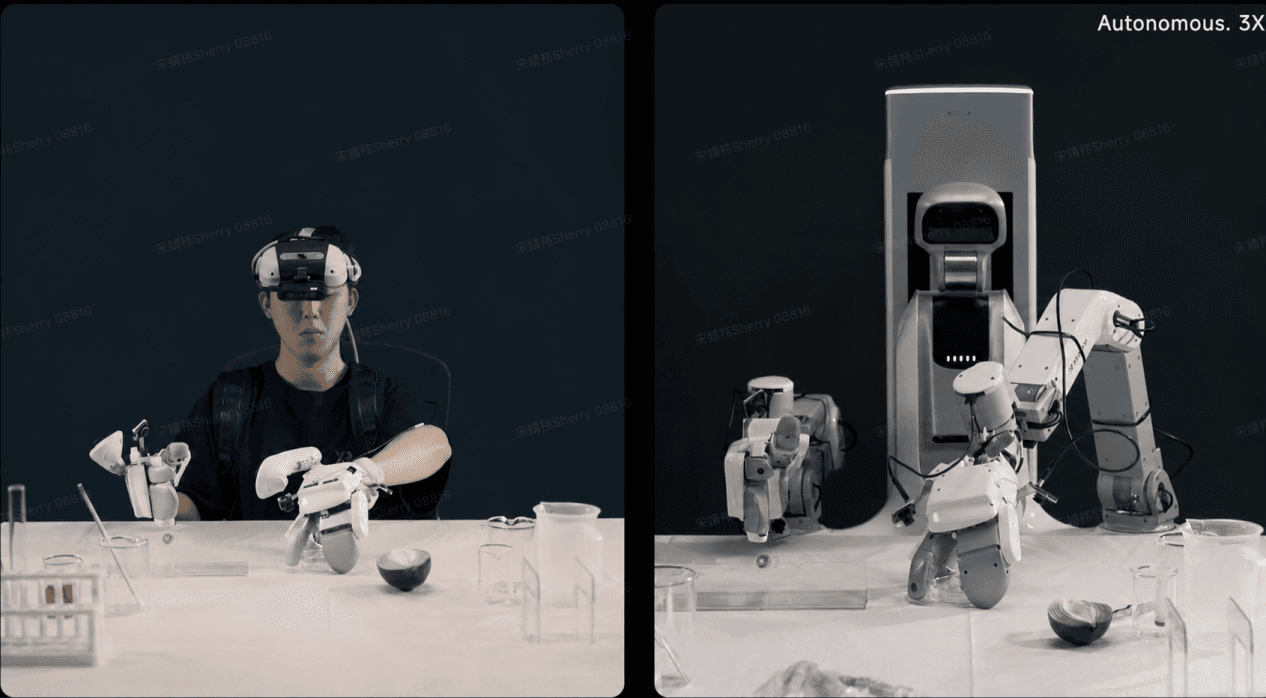


X Square Robot introduced TwinDEX, a co-designed dexterous manipulation system that connects robot-free data collection directly to real-world deployment. Its wearable collection device and robotic end effector share a three-finger, nine-DoF architecture, reducing the embodiment gap between demonstrations and robot execution. In testing, TwinDEX achieved up to 5.3× the effective data-collection throughput of on-robot teleoperation and enabled long-horizon, contact-rich manipulation from only a few hundred robot-free demonstrations.
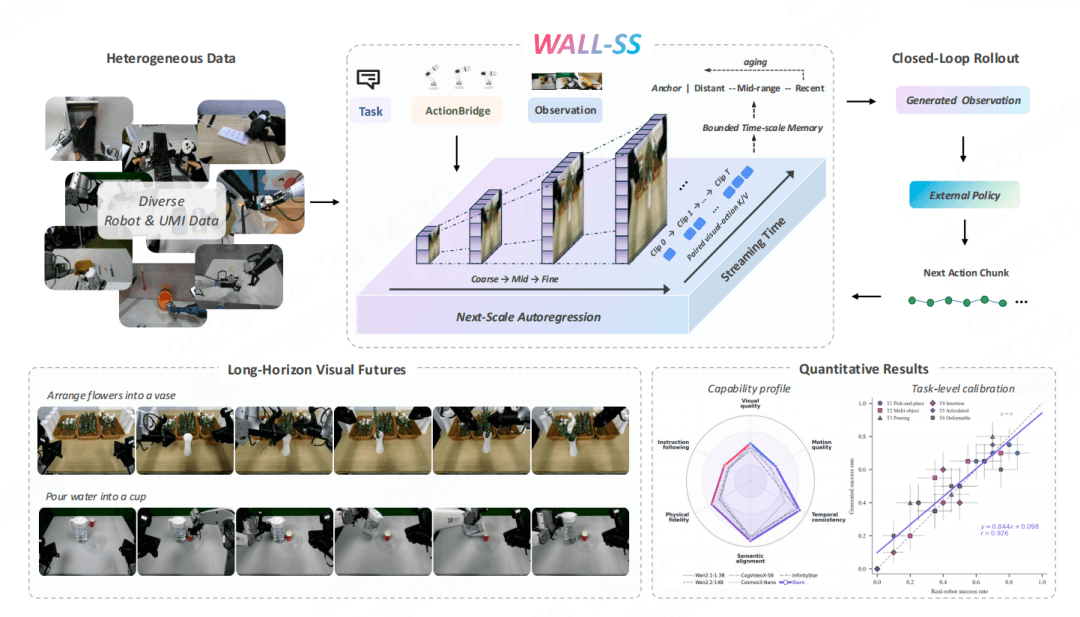
X Square Robot introduced WALL-SS, a next-scale autoregressive world model designed to improve action following, long-horizon simulation, and sim-to-real consistency. The model supports stable rollouts of up to 60 seconds and improves trajectory accuracy by about 115% over its backbone. In 600 paired simulated and real-world evaluations across six manipulation tasks, simulated policy success rates showed a 0.93 correlation with physical results, highlighting WALL-SS’s potential for robot policy evaluation and training. The research paper and code are open-sourced.
Highlighting the breadth of what WALL-B can enable and the depth of performance it can sustain in the physical world.
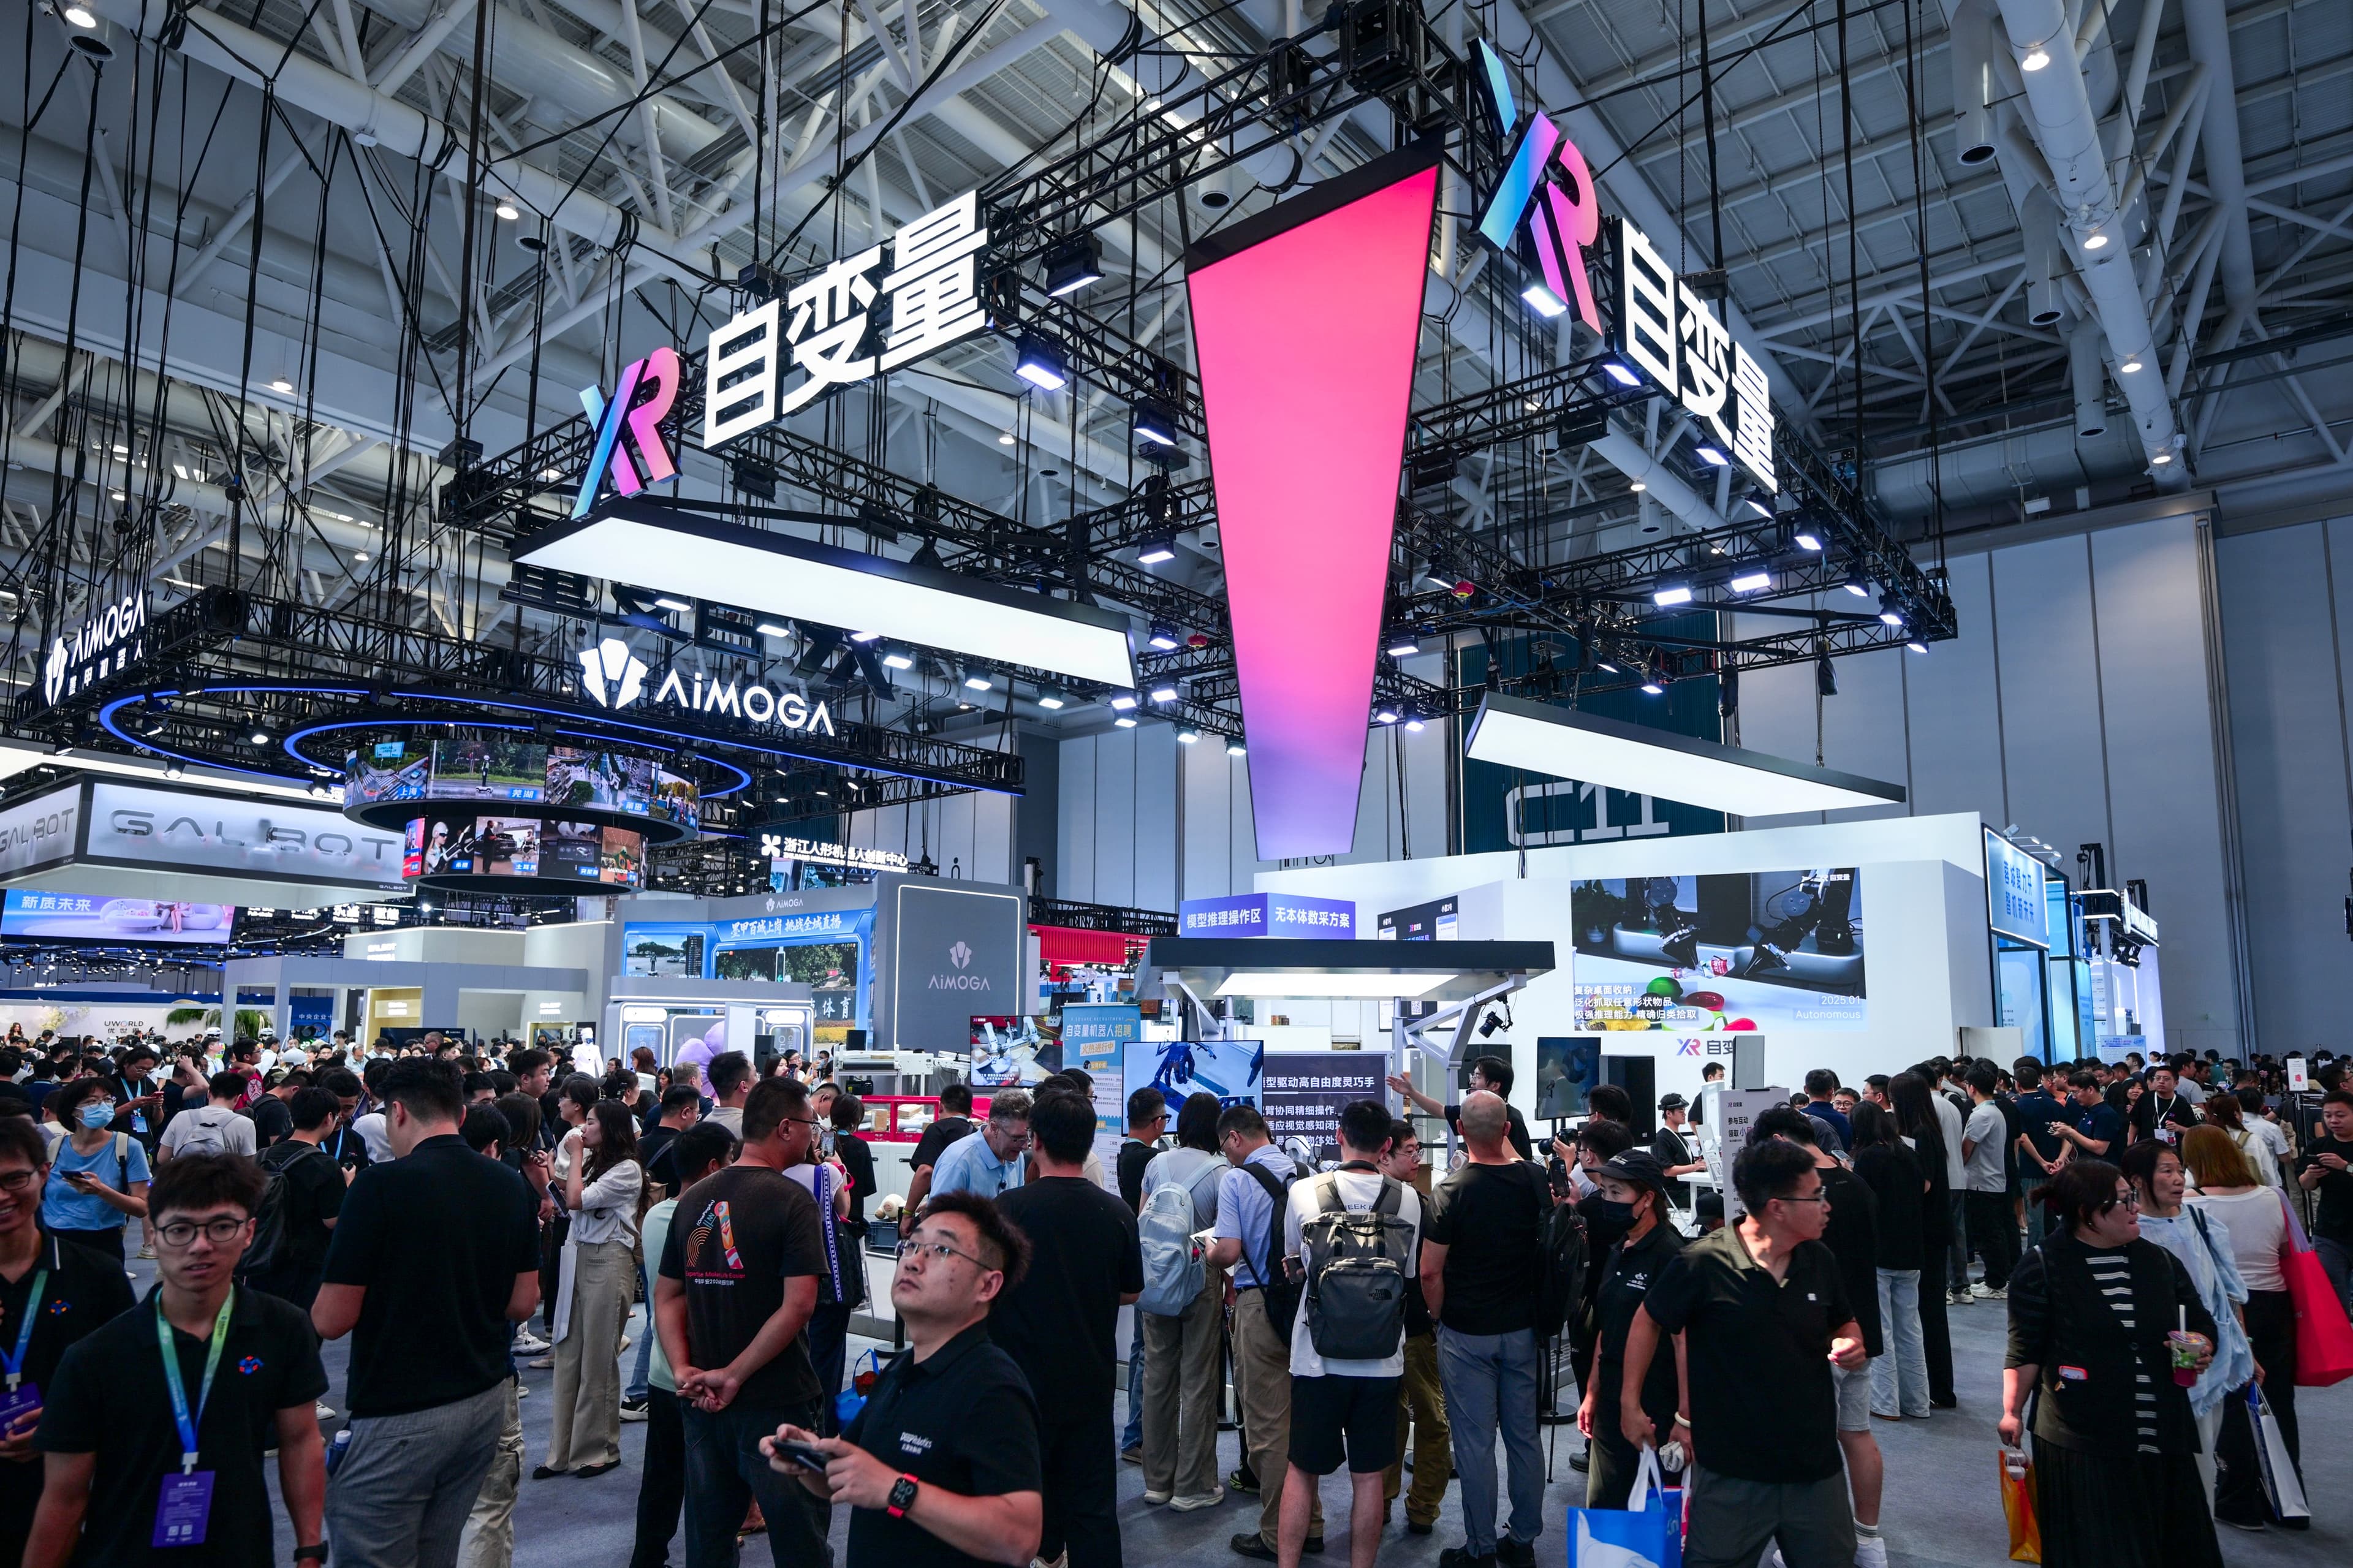
At 2026 WRC in Beijing, demonstrations show how embodied AI moves from data and skills to robots operating in logistics and real homes.
X Square Robot demonstrated its embodied AI system in a live logistics sorting operation, where its WALL-B foundation model and self-developed High-Performance 6-Axis Robot Arm autonomously handled highly variable parcels. The system achieved a throughput of 1,816 parcels per hour with over 98% accuracy, showcasing the potential of embodied AI for real-world logistics automation.
X Square Robot has open-sourced HOST, a framework that enables robots to learn new manipulation skills from a single 29-second human video without fine-tuning. By predicting task outcomes instead of directly imitating human motions, HOST achieves a 62% success rate, while using 50× less data and learning 507× faster than fine-tuning approaches.
X Square Robot Founder and CEO Wang Qian was invited to speak at the APEC High-Level Dialogue on Digital and AI Empowerment, held in Chengdu on July 24 as part of APEC Digital Week 2026.
X Square Robot has released DMuon, an open-source distributed implementation of the Muon optimizer that brings its per-step cost close to AdamW while preserving Muon's convergence behavior.
X Square Robot has released DMuon, an open-source distributed implementation of the Muon optimizer that brings its per-step cost close to AdamW while preserving Muon's convergence behavior.
X Square Robot Launches QUANXTA Zero Series, Reframing Embodied Data Production Through Universal Manipulation Interfaces