Product Overview
Learn about Quanta X1 Pro's product positioning, hardware components, specifications, and development board configuration.
This page introduces Quanta X1 Pro. Before starting development, check that the robot's capabilities, workspace, payload, and interfaces meet the requirements of your intended application.
Quanta X1 Pro
Quanta X1 Pro is a wheeled dual-arm embodied robot independently developed by X Square Robot. Its wheeled chassis and lightweight robotic arms provide flexible operation, covering a vertical operating space of 0–1.6 m.
The robot features a proprietary end-to-end embodied foundation model and supports multimodal teleoperation through VR, kinematically isomorphic teaching devices, and other methods. It can be used for autonomous inference, model validation, remote teleoperation, and data collection. Applications include research and education, logistics sorting, food delivery, sanitation and cleaning, and other scenarios.
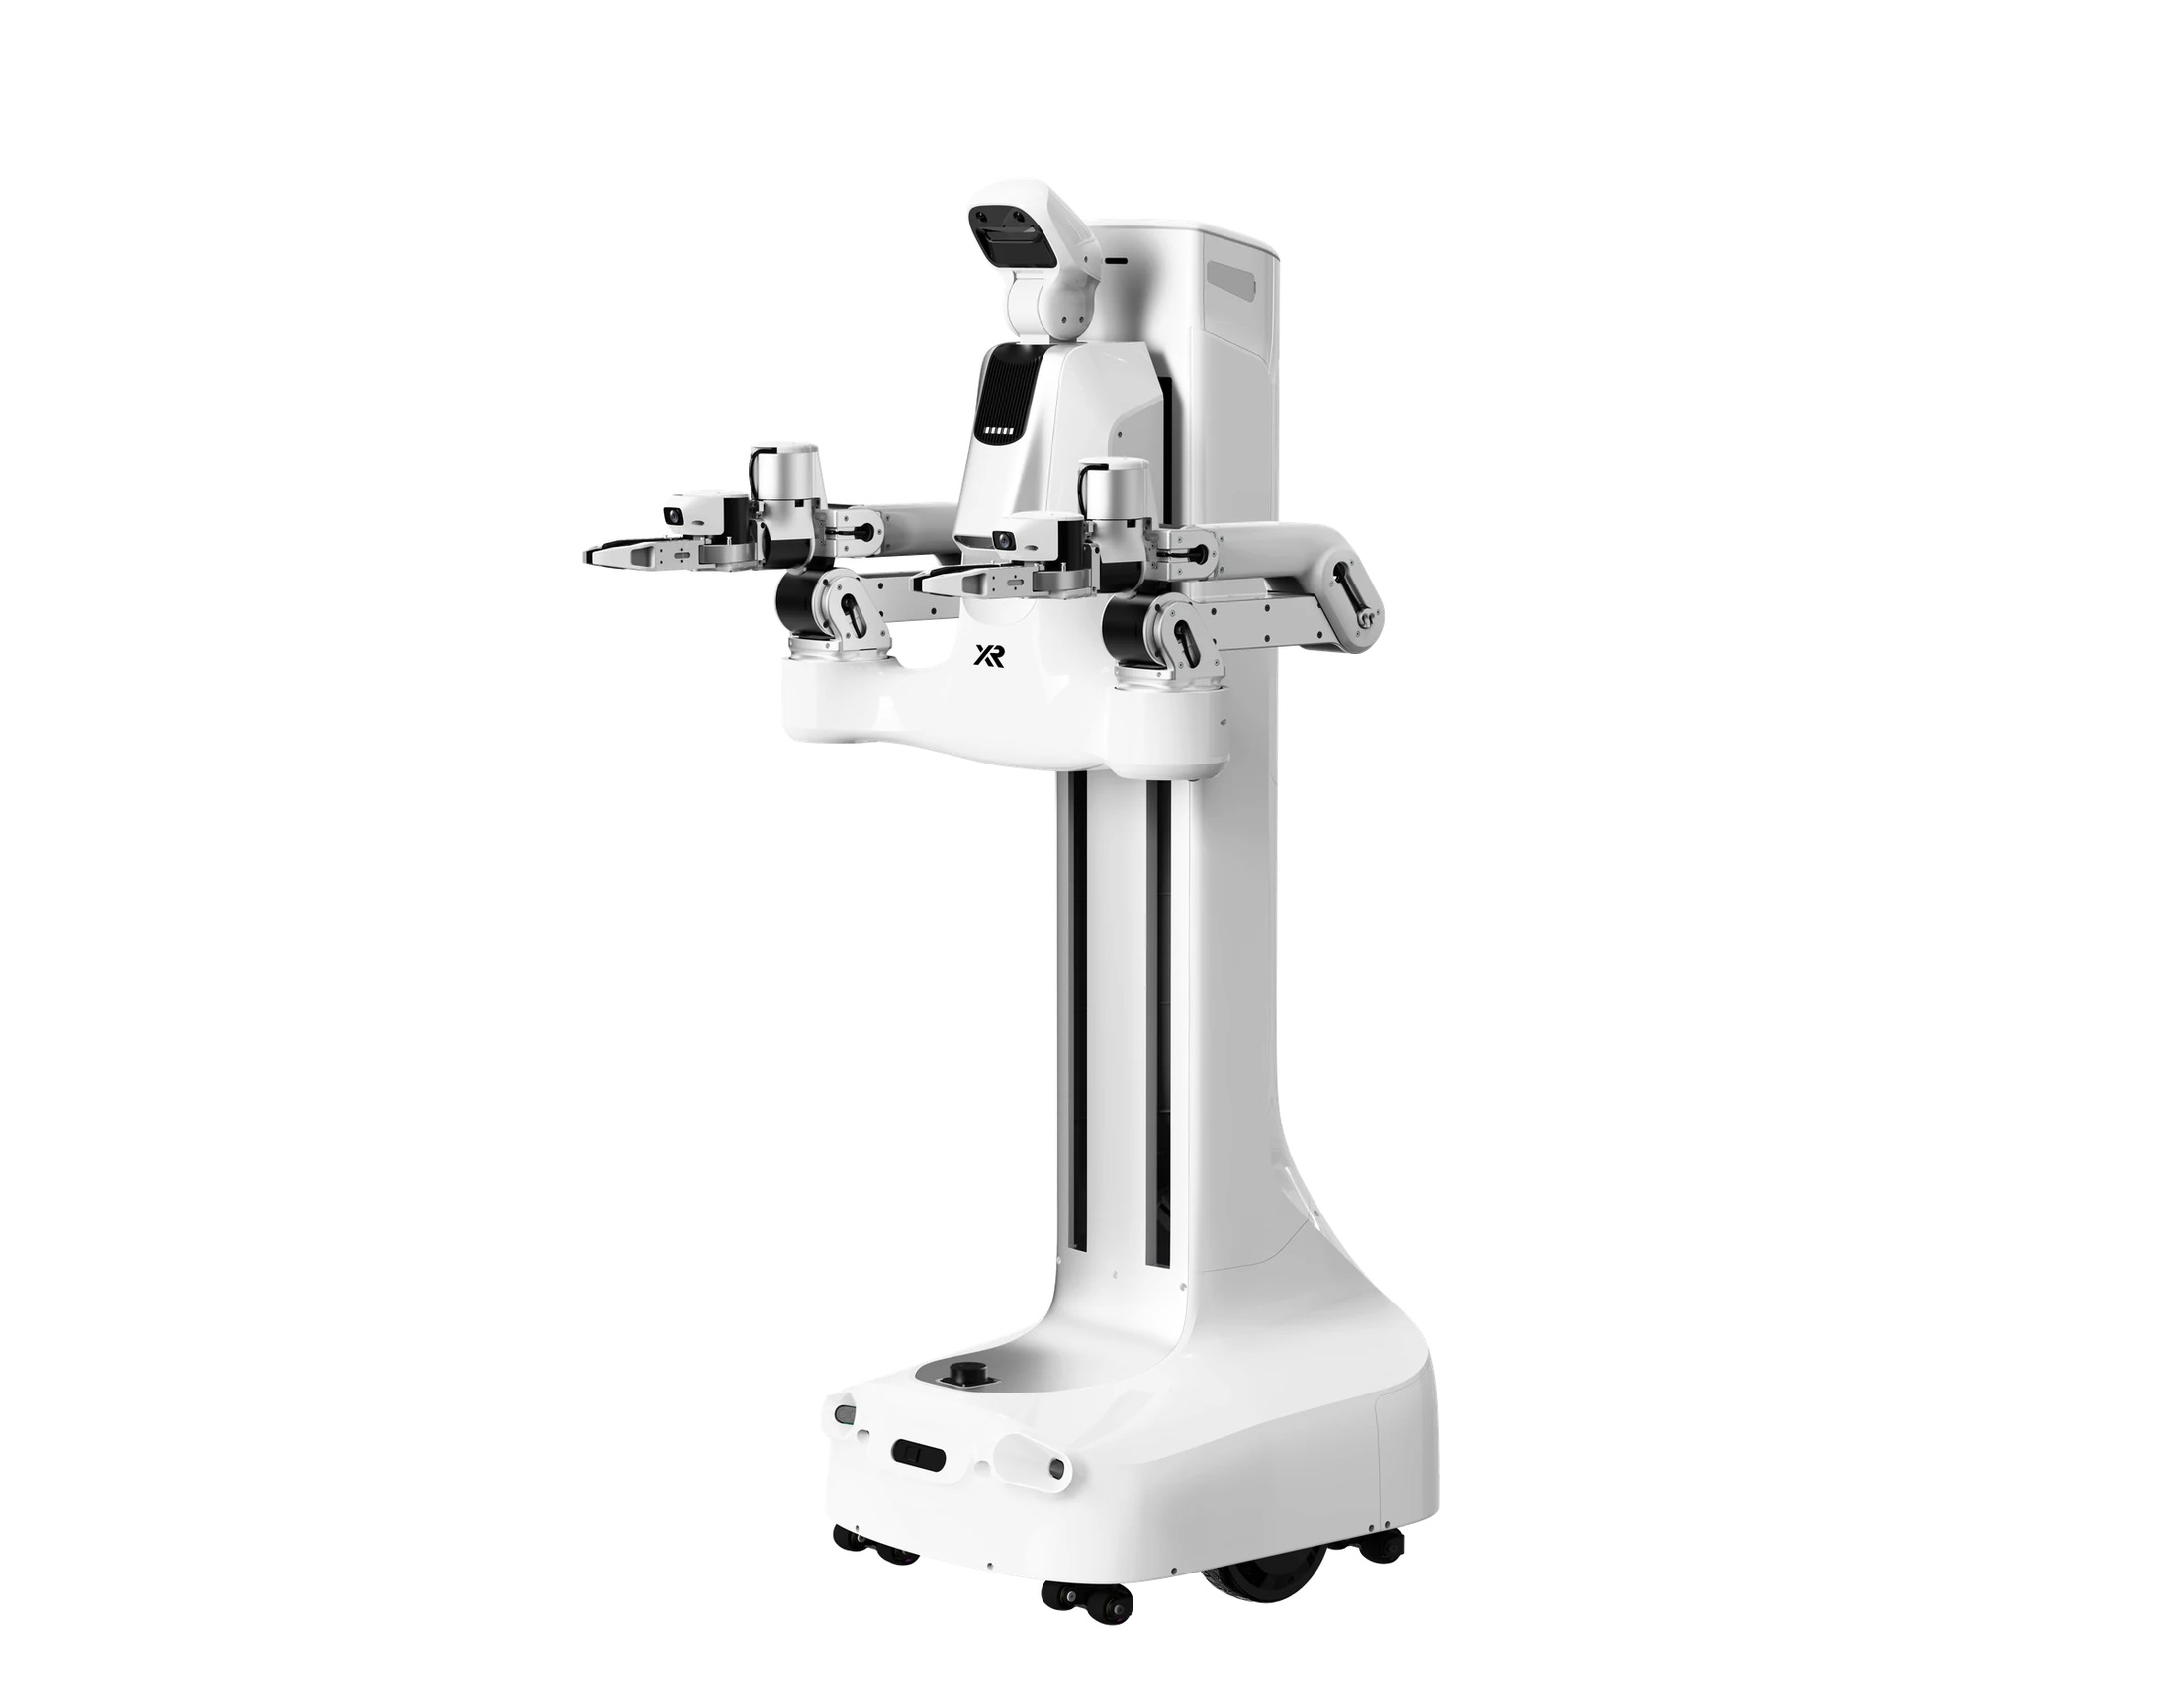
Quanta X1 Pro product appearance
Robot Specifications
| Type | Parameter | ||
|---|---|---|---|
| Basic parameters | Overall configuration | Wheeled mobile dual-arm robot | |
| Whole-body degrees of freedom | 19 | ||
| Maximum physical dimensions | Shoulder width 658mm; height 1690mm; chassis dimensions 511*618mm | ||
| Task payload capacity | 6kg (dual arms) | ||
| Vertical operating space | 0-1.6m | ||
| Mobile chassis | Degrees of freedom | 2 | |
| Mobility mode | Dual-wheel differential drive | ||
| Steering mode | Supports in-place steering | ||
| Chassis dimensions | 511*618mm | ||
| Maximum movement speed | 1m/s | ||
| Maximum obstacle traversal capability | 4cm | ||
| Maximum gradeability | 10° | ||
| Waist | Degrees of freedom | 1 | |
| Lifting stroke | 780mm | ||
| Lifting speed | 20cm/s | ||
| Head pan-tilt unit | Degrees of freedom | 2 | |
| Joint angle range | Pitch ±30°, yaw ±90° | ||
| Six-axis arm | Degrees of freedom | 6 | |
| Weight | 5kg | ||
| Maximum reach (per arm, excluding gripper) | 649mm | ||
| Rated payload | 3kg (excluding end-effector) | ||
| Maximum payload capacity | 7kg (30s, excluding end-effector) | ||
| Maximum end-effector speed | 2.5m/s | ||
| Repeatability | 1mm | ||
| Joint angle | J1: -160°~160°; J2: 0°~210°; J3: -160°~0; J4: -90°~90°; J5: -90°~90°; J6: -110°~110°; | ||
| Torque | J1-J3: 30Nm; J4-J6: 9Nm | ||
| End-effector G-type gripper | Gripper weight | 850g | |
| Opening and closing stroke | 0-180mm | ||
| Gripping length | 100mm | ||
| Maximum clamping force | 50N | ||
| Horizontal gripping payload (friction) | 2kg | ||
| Vertical gripping payload (form-fit) | 3kg | ||
| Gripper camera | Wide-angle camera; resolution 640x480 | ||
| Opening and closing speed | Within 1s | ||
| Communication method | Gripper: CAN; camera: USB | ||
| Perception system | Chassis | Single-point TOF | 2 units |
| 2D LiDAR | 1 unit | ||
| RGBD camera | 1 unit | ||
| IMU sensor | 1 unit | ||
| Forward ultrasonic sensor | 2 units | ||
| Rear ultrasonic sensor | 2 units | ||
| Chest | RGBD camera | 1 unit | |
| Single-point TOF | 1 unit | ||
| Elbow | Fisheye camera | 2 units | |
| Ultrasonic sensor | 2 units | ||
| Head | RGBD camera | 1 unit | |
| Binocular RGB camera | 1 unit | ||
| Wrist | Wide-angle camera | 2 units | |
| Wireless | Wi-Fi | Supports Wi-Fi 6, 2.4/5 GHz dual-band | |
| Bluetooth | Supports Bluetooth 5.2 | ||
| Mobile Network | Supports 5G | ||
| Wired | Interface | HDMI * 1, USB * 1, RJ45 * 1 | |
Development Board Specifications
| Component | Details |
|---|---|
| CPU | Intel Core Ultra 7 |
| RAM | 16GB |
| Storage | 512GB |
Overall Dimensions
The robot's appearance may vary slightly between product versions.
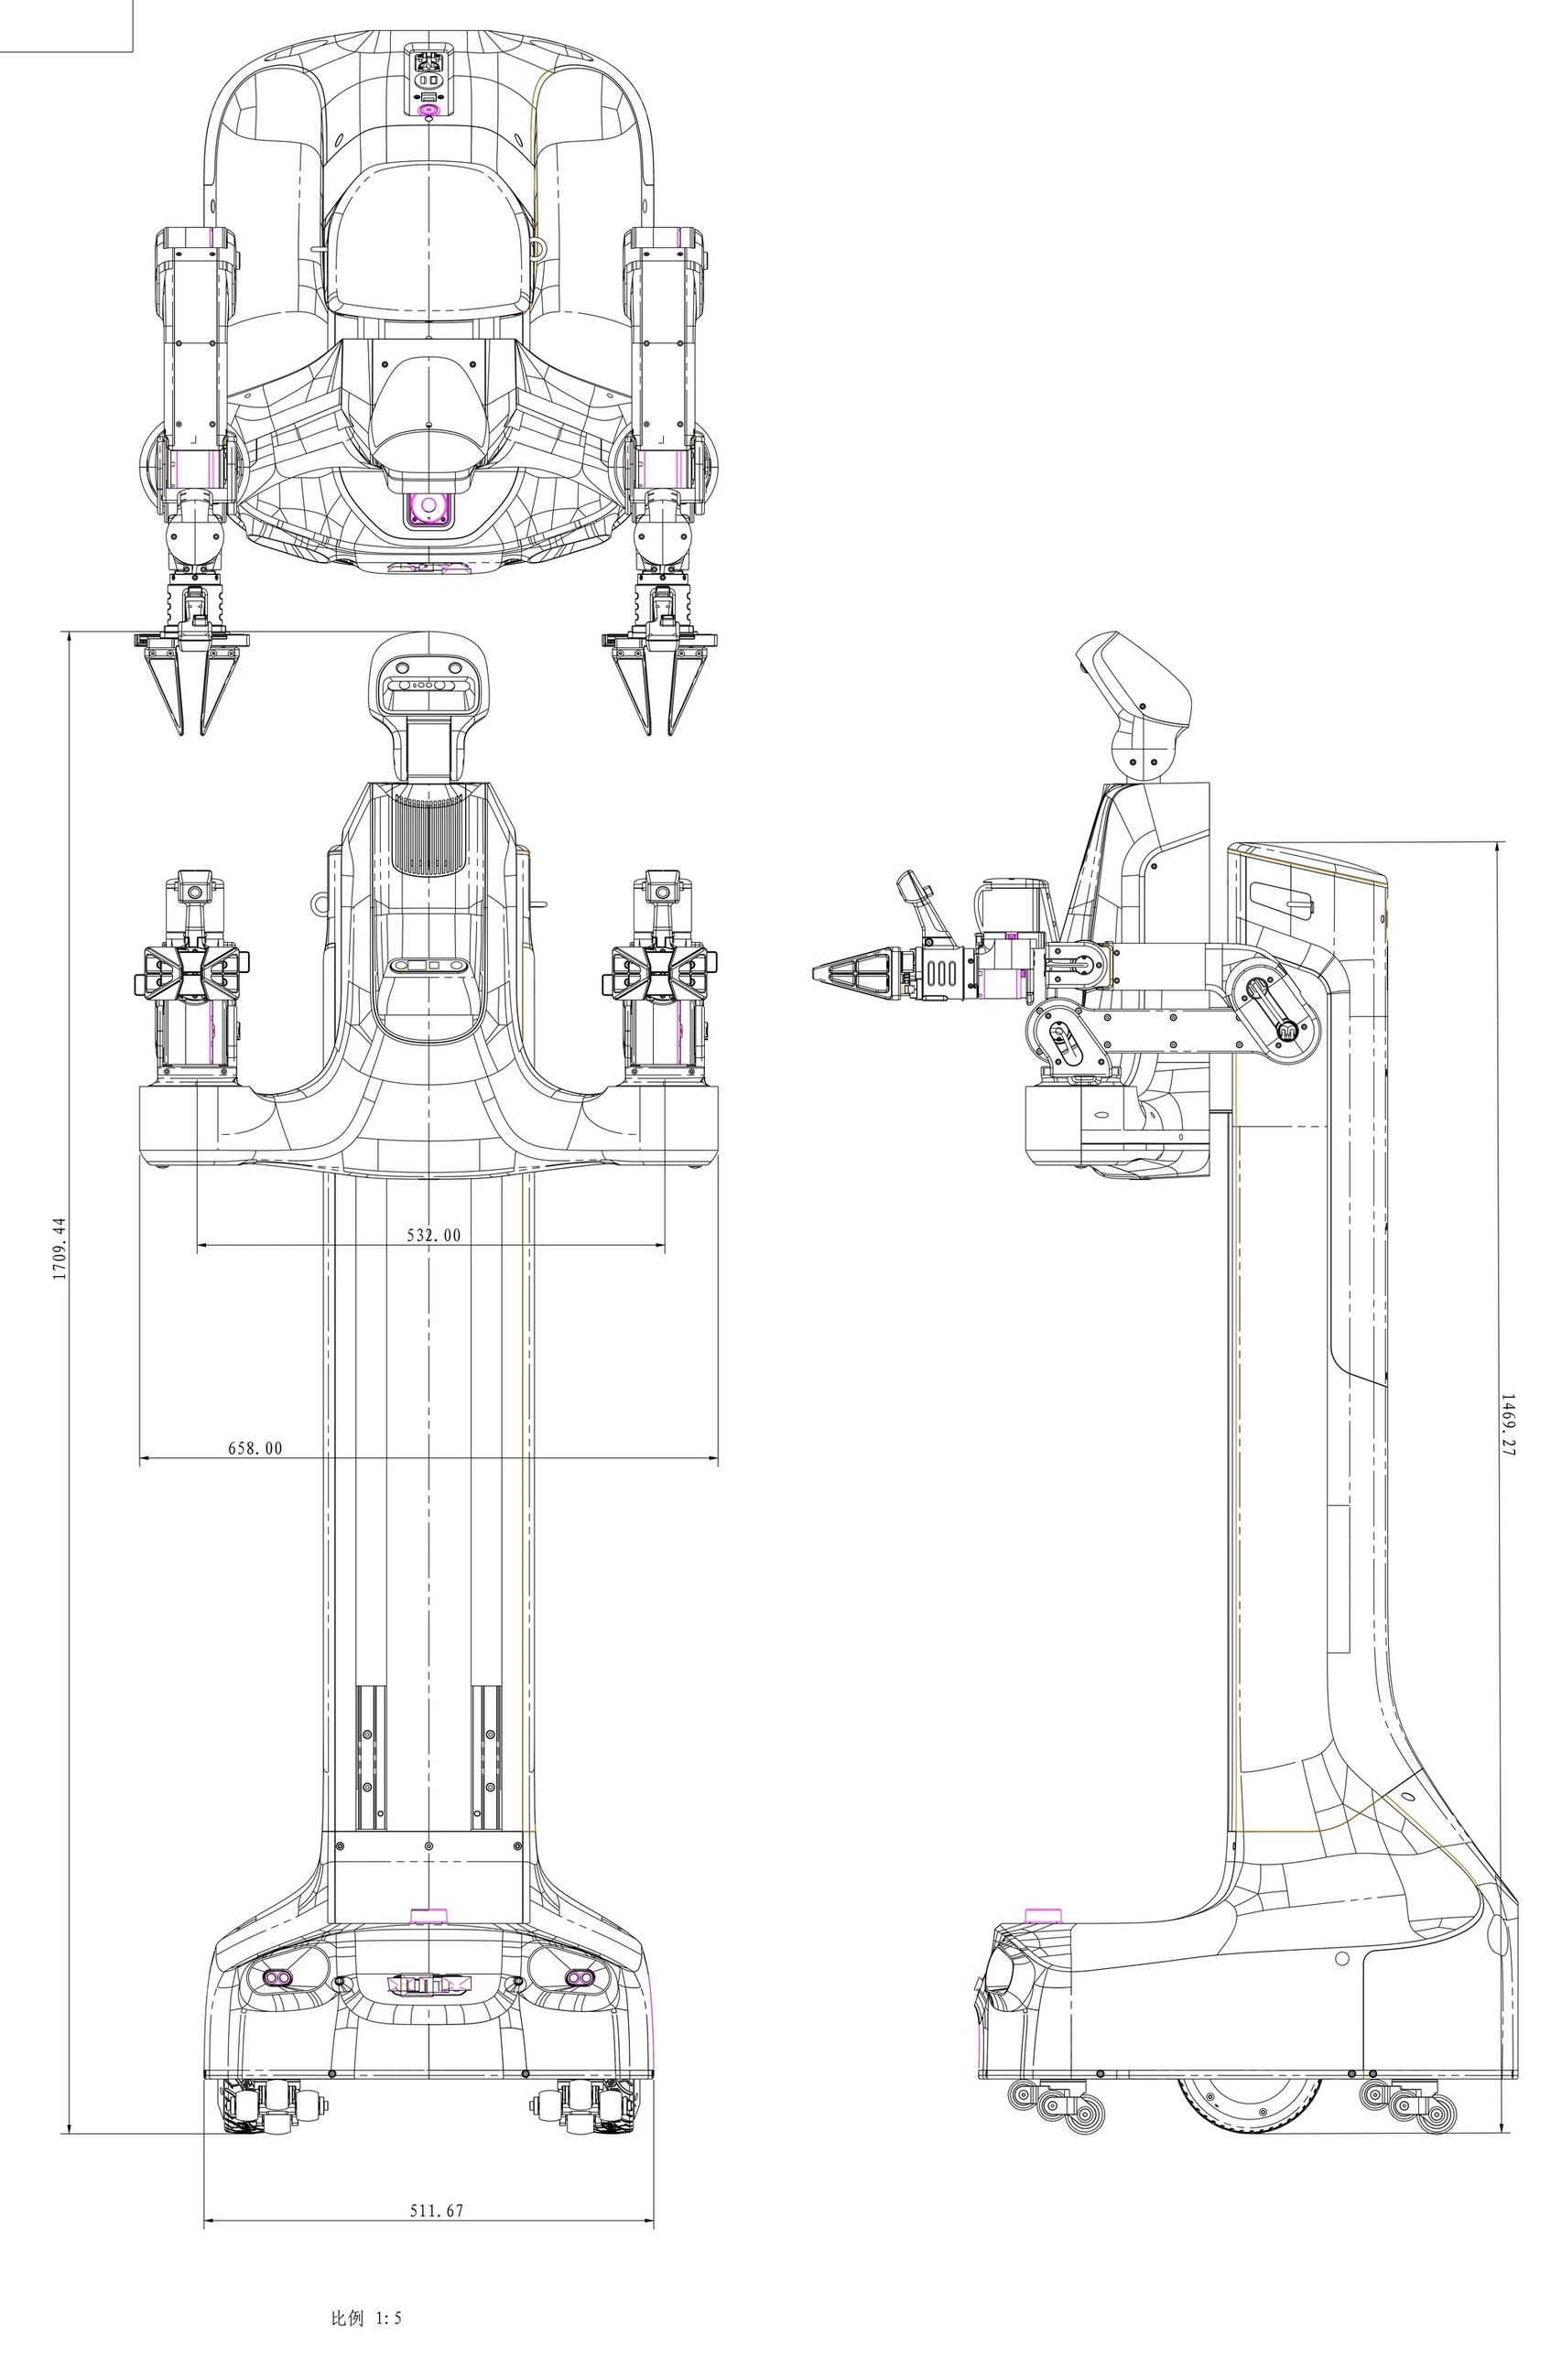
Quanta X1 Pro overall dimension diagram
Robot Sensor Layout
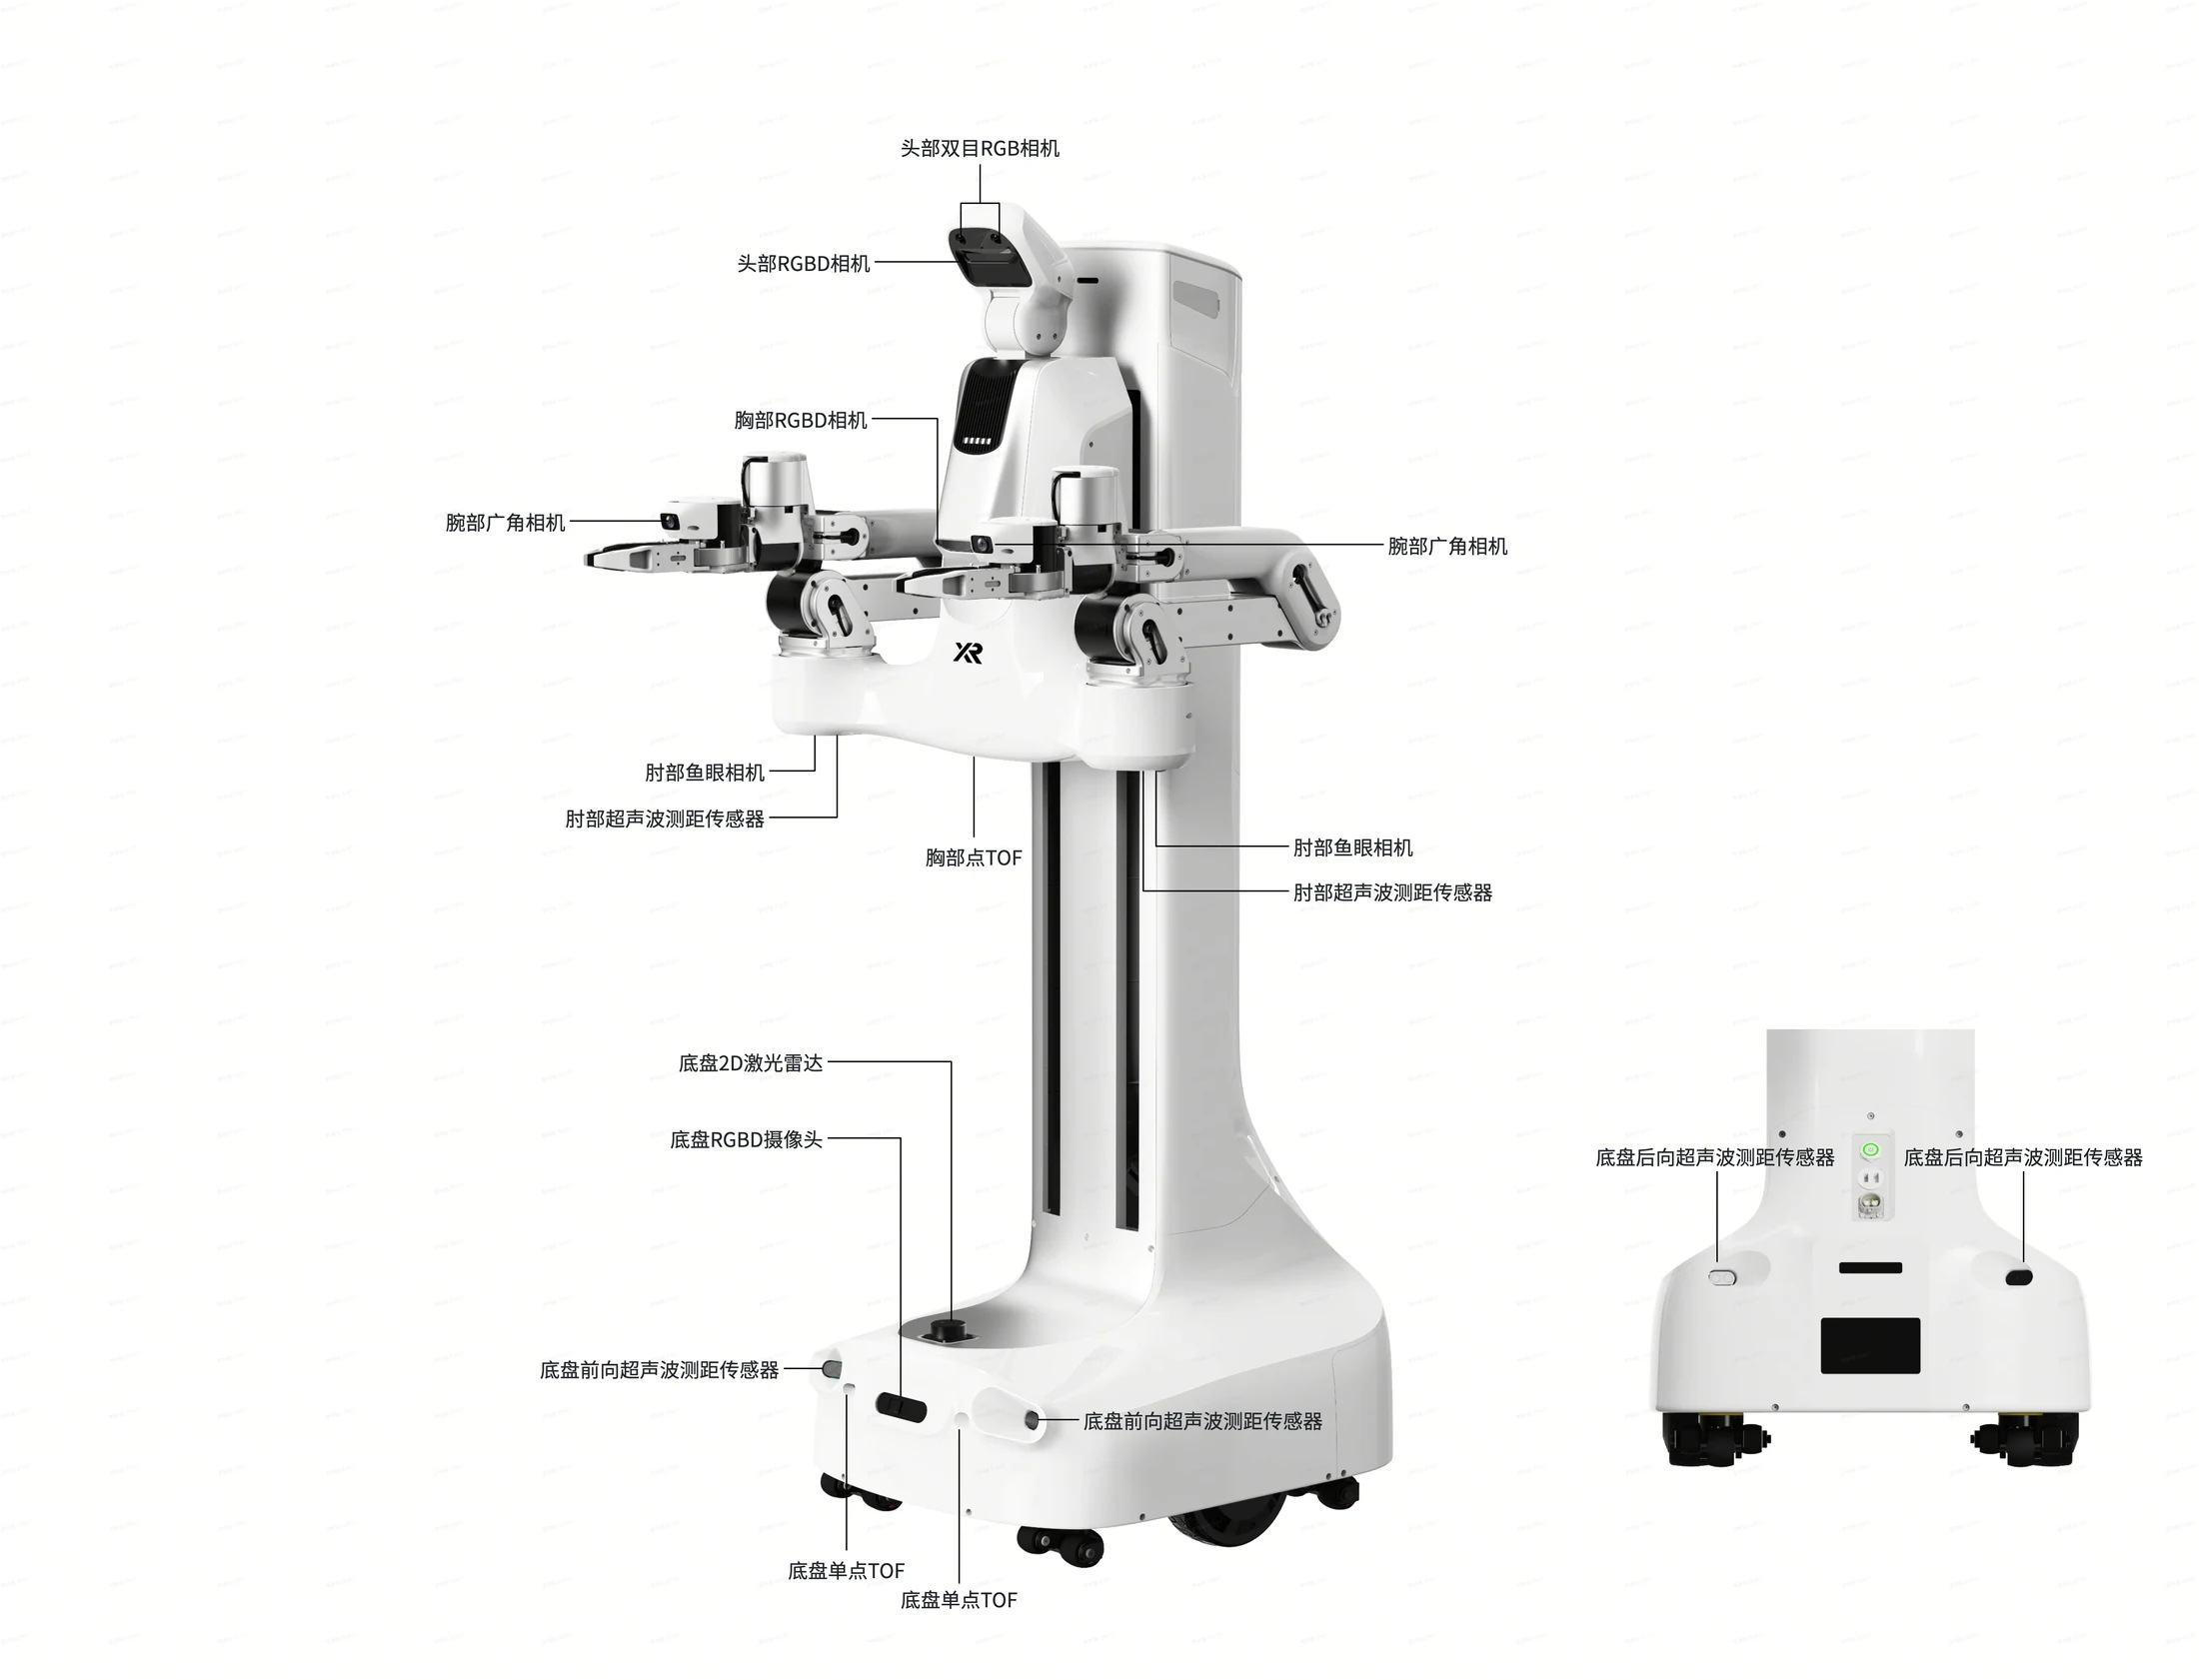
Quanta X1 Pro robot sensor layout
Joint Range of Motion
The joint rotation coordinate systems of Quanta X1 Pro use a right-handed coordinate system. In the figure, the X-axis is shown in red, the Y-axis in green, and the Z-axis in blue; rotations around the X, Y, and Z axes correspond to Roll, Pitch, and Yaw, respectively; dots represent joint rotation centers or zero positions.
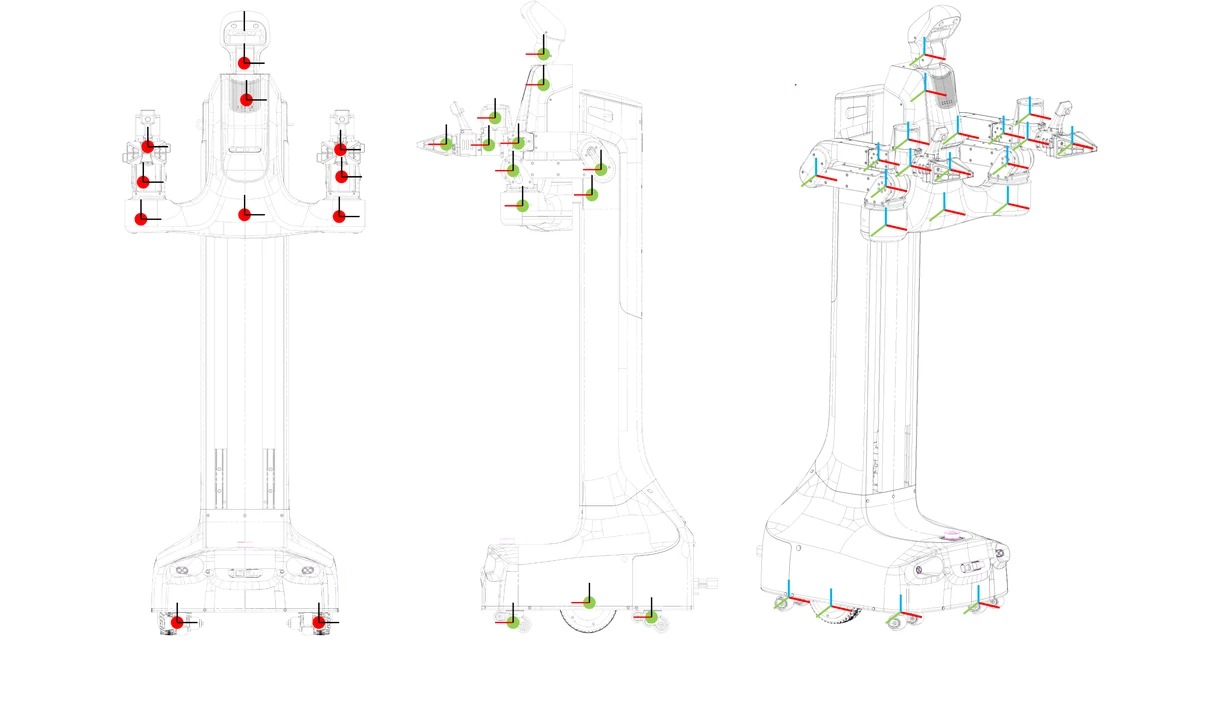
Quanta X1 Pro joint rotation coordinate systems and zero positions